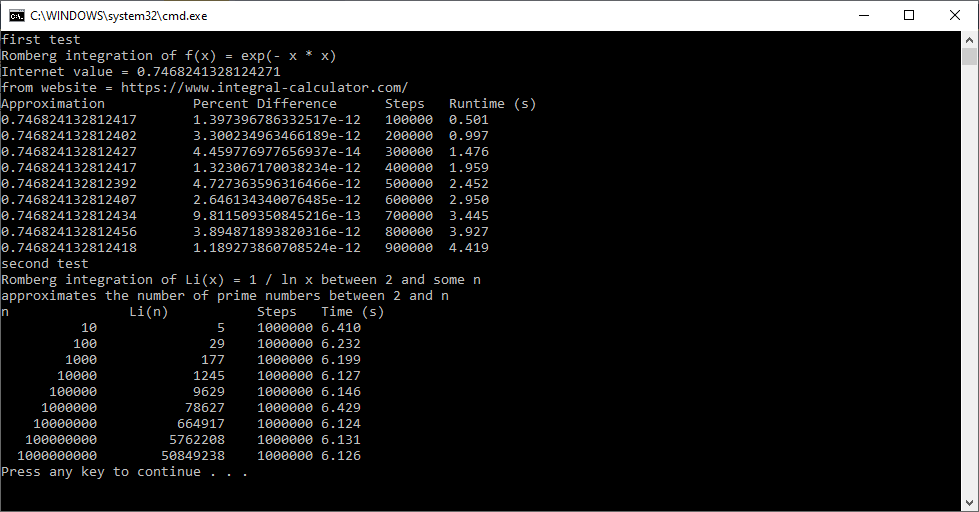
Comparison of Euler Method, Runge-Kutta 2, Runge-Kutta 4, and Taylor Series Solutions of a Single Ordinary Differential Equation

#include "RungeKutta4.h"
#include <iomanip>
#include <iostream>
using namespace std;

int main()
{
	int nSteps;
	vector<Point> solution1, solution2;
	vector<Point> solution3, solution4;

	while (true)
	{
		cout << "n-steps (zero to exit app) = ";
		cin >> nSteps;

		if (nSteps == 0)
			break;

		cout << "n\t\txn\tyn2p(xn)\tyn4p(xn)\tEuler\t\tTaylor\t\tDFDX2\t\tDFDX4\r\n";
		RungeKutta4::ComputeEuler(nSteps, 1, 2, -1, solution1);
		RungeKutta4::ComputeRK2(nSteps, 1, 2, -1, solution2);
		RungeKutta4::ComputeRK4(nSteps, 1, 2, -1, solution3);
		RungeKutta4::ComputeTaylor(nSteps, 1, 2, -1, solution4);

		for (int i = 0; i <= nSteps; i++)
		{
			POINT pt1 = solution1[i];
			POINT pt2 = solution2[i];
			POINT pt3 = solution3[i];
			POINT pt4 = solution4[i];
			cout << setw(2) << pt1.n << "\t";
			cout << setprecision(8) << fixed << pt1.x << "\t";
			cout << setprecision(8) << fixed << pt3.y << "\t";
			cout << setprecision(8) << fixed << pt4.y << "\t";
			cout << setprecision(8) << fixed << pt1.y << "\t";
			cout << setprecision(8) << fixed << pt2.y << "\t";
			cout << setprecision(8) << fixed << pt2.derivative << "\t";
			cout << setprecision(8) << fixed << pt3.derivative << "\r\n";
		}
	}
}
#pragma once
#include <vector>
using namespace std;

typedef struct Point
{
	int n;
	long double derivative, x, y;
} POINT, *PPOINT;

class RungeKutta4
{
private:
	static long double FX(
		long double x,
		long double y);
	static long double DFDX(
		long double x,
		long double y,
		long double yp);
public:
	static void ComputeEuler(
		int nSteps,
		long double x0,
		long double x1,
		long double y0,
		vector<Point>& pts);
	static void ComputeRK2(
		int nSteps,
		long double x0,
		long double x1,
		long double y0,
		vector<Point>& pts);
	static void ComputeRK4(
		int nSteps,
		long double x0,
		long double x1,
		long double y0,
		vector<Point>& pts);
	static void ComputeTaylor(
		int nSteps,
		long double x0,
		long double x1,
		long double y0,
		vector<Point>& pts);
};
// Translated from FORTRAN 77 source code found
// in "Elementary Numerical Analysis:
// An Algorithmic Approach" by S. D. Conte and Carl de
// Boor. Translator: James Pate Williams, Jr. (c)
// August 20, 2023

#include "RungeKutta4.h"

long double RungeKutta4::FX(
	long double x, long double y)
{
	long double x2 = x * x;
	long double term1 = 1.0 / x2;
	long double term2 = -y / x;
	long double term3 = -y * y;
	return term1 + term2 + term3;
}

long double RungeKutta4::DFDX(
	long double x,
	long double y,
	long double yp)
{
	long double x3 = x * x * x;
	long double term1 = -2.0 / x3;
	long double term2 = -yp / x;
	long double term3 = y / x / x;
	long double term4 = -2.0 * y * yp;
	return term1 + term2 + term3 + term4;
}

void RungeKutta4::ComputeEuler(
	int nSteps,
	long double x0,
	long double x1,
	long double y0,
	vector<Point>& pts)
{
	Point pt0 = {};
	pt0.n = 0;
	pt0.x = x0;
	pt0.y = y0;
	double derivative = FX(x0, y0);
	pt0.derivative = derivative;
	pts.push_back(pt0);

	if (nSteps == 1)
		return;

	long double h = (x1 - x0) / nSteps;
	long double xn = x0;
	long double yn = y0;

	for (int n = 1; n <= nSteps; n++)
	{
		xn = x0 + n * h;
		long double yn = y0 + h * FX(xn, y0);
		derivative = FX(xn, y0);
		pt0.n = n;
		pt0.derivative = derivative;
		pt0.x = xn;
		pt0.y = yn;
		pts.push_back(pt0);
		y0 = yn;
	}
}

void RungeKutta4::ComputeRK2(
	int nSteps,
	long double x0,
	long double x1,
	long double y0,
	vector<Point>& pts)
{
	Point pt0 = {};
	pt0.n = 0;
	pt0.x = x0;
	pt0.y = y0;
	double derivative = FX(x0, y0);
	pt0.derivative = derivative;
	pts.push_back(pt0);

	if (nSteps == 1)
		return;

	long double h = (x1 - x0) / nSteps;
	long double xn = x0;
	long double yn = y0;

	for (int n = 1; n <= nSteps; n++)
	{
		long double k1 = h * FX(xn, yn);
		long double k2 = h * FX(xn + h, yn + k1);
		yn += 0.5 * (k1 + k2);
		xn = x0 + n * h;
		derivative = FX(xn, yn);
		pt0.n = n;
		pt0.derivative = derivative;
		pt0.x = xn;
		pt0.y = yn;
		pts.push_back(pt0);
	}
}

void RungeKutta4::ComputeRK4(
	int nSteps,
	long double x0,
	long double x1,
	long double y0,
	vector<Point>& pts)
{
	Point pt0 = {};
	pt0.n = 0;
	pt0.x = x0;
	pt0.y = y0;
	double derivative = FX(x0, y0);
	pt0.derivative = derivative;
	pts.push_back(pt0);

	if (nSteps == 1)
		return;

	long double h = (x1 - x0) / nSteps;
	long double xn = x0;
	long double yn = y0;

	for (int n = 1; n <= nSteps; n++)
	{
		long double k1 = h * FX(xn, yn);
		long double k2 = h * FX(xn + h / 2, yn + k1 / 2);
		long double k3 = h * FX(xn + h / 2, yn + k2 / 2);
		long double k4 = h * FX(xn + h, yn + k3);
		xn = x0 + n * h;
		yn = yn + (k1 + k2 + k3 + k4) / 6.0;
		derivative = FX(xn, yn);
		pt0.n = n;
		pt0.derivative = derivative;
		pt0.x = xn;
		pt0.y = yn;
		pts.push_back(pt0);
	}
}

void RungeKutta4::ComputeTaylor(
	int nSteps,
	long double x0,
	long double x1,
	long double y0,
	vector<Point>& pts)
{
	Point pt0 = {};
	pt0.n = 0;
	pt0.x = x0;
	pt0.y = y0;
	double derivative = FX(x0, y0);
	pt0.derivative = derivative;
	pts.push_back(pt0);

	if (nSteps == 1)
		return;

	long double h = (x1 - x0) / nSteps;
	long double xn = x0;
	long double yn = y0;
	long double yp = FX(x0, y0);

	for (int n = 1; n <= nSteps; n++)
	{
		xn = x0 + n * h;
		yp = FX(xn, y0);
		long double yn = y0 + h * (FX(xn, y0) + h * DFDX(xn, y0, yp) / 2);
		derivative = FX(xn, y0);
		pt0.n = n;
		pt0.derivative = derivative;
		pt0.x = xn;
		pt0.y = yn;
		pts.push_back(pt0);
		y0 = yn;
	}
}

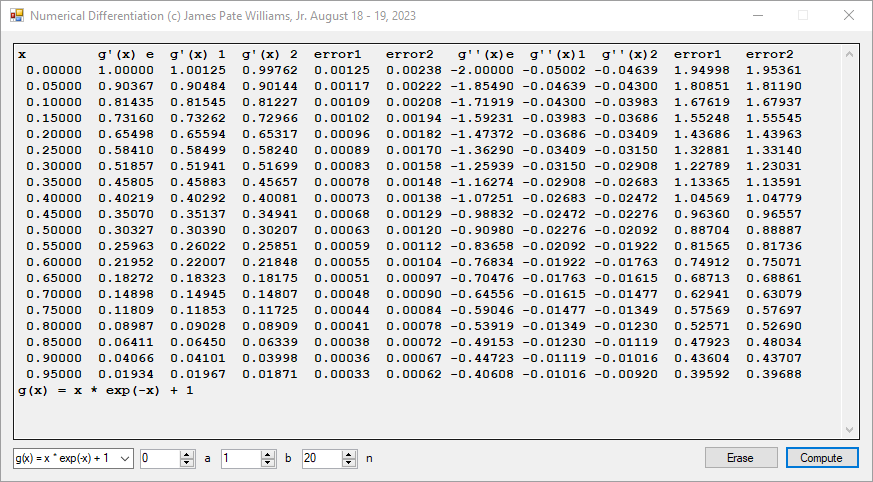
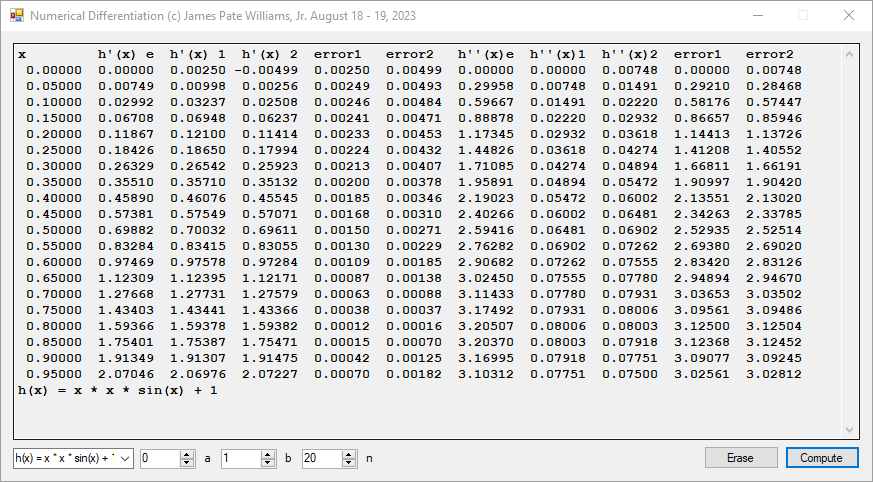
Numerical Differentiation in C# by James Pate Williams, Jr. Translated from FORTRAN 77 Formulas

using System;
using System.Windows.Forms;

namespace NumericalDifferentiation
{
    public partial class Form1 : Form
    {
        public Form1()
        {
            InitializeComponent();
            comboBox1.SelectedIndex = 0;
        }

        private double F1(double x)
        {
            return x * (x * (x - 2) + 4) - 1;
        }

        private double F2(double x)
        {
            return x * Math.Exp(-x) + 1;
        }

        private double F3(double x)
        {
            return x * x * Math.Sin(x) + 1;
        }

        private double DF1(double x)
        {
            return 3 * x * x - 4 * x + 4; 
        }

        private double DF2(double x)
        {
            return Math.Exp(-x) - x * Math.Exp(-x);
        }

        private double DF3(double x)
        {
            return 2 * x * Math.Sin(x) + x * x * Math.Cos(x);
        }

        private double DDF1(double x)
        {
            return 6 * x - 4;
        }

        private double DDF2(double x)
        {
            return -2 * Math.Exp(-x) + x * Math.Exp(-x);
        }

        private double DDF3(double x)
        {
            return
                2 * Math.Sin(x) + 2 * x * Math.Cos(x) +
                2 * x * Math.Cos(x) - x * x * Math.Sin(x);
        }

        private void button1_Click(object sender, EventArgs e)
        {
            double a = (double)numericUpDown1.Value;
            double b = (double)numericUpDown2.Value;
            int n = (int)numericUpDown3.Value;
            double deriv1c, deriv1f;
            double deriv2c, deriv2f;
            double x = a, y, u, v;
            double error1c, error1f, error2c, error2f;
            double h = (b - a) / n;

            if (comboBox1.SelectedIndex == 0)
                textBox1.Text += "x\t  f'(x) e  f'(x) 1  f'(x) 2  " +
                    "error1   error2   f''(x)e  f''(x)1  f''(x)2  " +
                    "error1   error2\r\n";
            else if (comboBox1.SelectedIndex == 1)
                textBox1.Text += "x\t  g'(x) e  g'(x) 1  g'(x) 2  " +
                    "error1   error2   g''(x)e  g''(x)1  g''(x)2  " +
                    "error1   error2\r\n";
            else if (comboBox1.SelectedIndex == 2)
                textBox1.Text += "x\t  h'(x) e  h'(x) 1  h'(x) 2  " +
                    "error1   error2   h''(x)e  h''(x)1  h''(x)2  " +
                    "error1   error2\r\n";

            while (x <= b)
            {
                switch (comboBox1.SelectedIndex)
                {
                    case 0:
                        y = F1(x);
                        u = DF1(x);
                        v = DDF1(x);
                        deriv1c = Differentiation.Derivative1sc(x, h, F1);
                        deriv1f = Differentiation.Derivative1sf(x, h, F1);
                        deriv2c = Differentiation.Derivative2sc(x, h, F1);
                        deriv2f = Differentiation.Derivative2sf(x, h, F1);
                        error1c = Math.Abs(deriv1c - u);
                        error1f = Math.Abs(deriv1f - u);
                        error2c = Math.Abs(deriv2c - v);
                        error2f = Math.Abs(deriv2f - v);
                        textBox1.Text +=
                            x.ToString("F5").PadLeft(8) + " " +
                            u.ToString("F5").PadLeft(8) + " " +
                            deriv1c.ToString("F5").PadLeft(8) + " " +
                            deriv1f.ToString("F5").PadLeft(8) + " " +
                            error1c.ToString("F5").PadLeft(8) + " " +
                            error1f.ToString("F5").PadLeft(8) + " " +
                            v.ToString("F5").PadLeft(8) + " " +
                            deriv2c.ToString("F5").PadLeft(8) + " " +
                            deriv2f.ToString("F5").PadLeft(8) + " " +
                            error2c.ToString("F5").PadLeft(8) + " " +
                            error2f.ToString("F5").PadLeft(8) + "\r\n";
                        break;
                    case 1:
                        y = F2(x);
                        u = DF2(x);
                        v = DDF2(x);
                        deriv1c = Differentiation.Derivative1sc(x, h, F2);
                        deriv1f = Differentiation.Derivative1sf(x, h, F2);
                        deriv2c = Differentiation.Derivative2sc(x, h, F2);
                        deriv2f = Differentiation.Derivative2sf(x, h, F2);
                        error1c = Math.Abs(deriv1c - u);
                        error1f = Math.Abs(deriv1f - u);
                        error2c = Math.Abs(deriv2c - v);
                        error2f = Math.Abs(deriv2f - v);
                        textBox1.Text +=
                            x.ToString("F5").PadLeft(8) + " " +
                            u.ToString("F5").PadLeft(8) + " " +
                            deriv1c.ToString("F5").PadLeft(8) + " " +
                            deriv1f.ToString("F5").PadLeft(8) + " " +
                            error1c.ToString("F5").PadLeft(8) + " " +
                            error1f.ToString("F5").PadLeft(8) + " " +
                            v.ToString("F5").PadLeft(8) + " " +
                            deriv2c.ToString("F5").PadLeft(8) + " " +
                            deriv2f.ToString("F5").PadLeft(8) + " " +
                            error2c.ToString("F5").PadLeft(8) + " " +
                            error2f.ToString("F5").PadLeft(8) + "\r\n";
                        break;
                    case 2:
                        y = F3(x);
                        u = DF3(x);
                        v = DDF3(x);
                        deriv1c = Differentiation.Derivative1sc(x, h, F3);
                        deriv1f = Differentiation.Derivative1sf(x, h, F3);
                        deriv2c = Differentiation.Derivative2sc(x, h, F3);
                        deriv2f = Differentiation.Derivative2sf(x, h, F3);
                        error1c = Math.Abs(deriv1c - u);
                        error1f = Math.Abs(deriv1f - u);
                        error2c = Math.Abs(deriv2c - v);
                        error2f = Math.Abs(deriv2f - v);
                        textBox1.Text +=
                            x.ToString("F5").PadLeft(8) + " " +
                            u.ToString("F5").PadLeft(8) + " " +
                            deriv1c.ToString("F5").PadLeft(8) + " " +
                            deriv1f.ToString("F5").PadLeft(8) + " " +
                            error1c.ToString("F5").PadLeft(8) + " " +
                            error1f.ToString("F5").PadLeft(8) + " " +
                            v.ToString("F5").PadLeft(8) + " " +
                            deriv2c.ToString("F5").PadLeft(8) + " " +
                            deriv2f.ToString("F5").PadLeft(8) + " " +
                            error2c.ToString("F5").PadLeft(8) + " " +
                            error2f.ToString("F5").PadLeft(8) + "\r\n";                   
                        break;
                    default:
                        break;
                }

                x += h;
            }

            textBox1.Text += comboBox1.SelectedItem;
        }

        private void button2_Click(object sender, EventArgs e)
        {
            textBox1.Text = string.Empty;
        }
    }
}
// Derivative formulas translated from FORTRAN 77
// source code found in "Elementary Numerical Analysis:
// An Algorithmic Approach" by S. D. Conte and Carl de
// Boor. Translator: James Pate Williams, Jr. (c)
// August 18 - 19, 2023

using System;

namespace NumericalDifferentiation
{
    // Numerically compute first and second
    // ordinary derivatives
    class Differentiation
    {
        static public double Derivative1sc(
            double a, double h, Func<double, double> f)
        {
            return (f(a + h) - f(a - h)) / (h + h);
        }

        static public double Derivative1sf(
            double a, double h, Func<double, double> f)
        {
            return (-3.0 * f(a) + 4.0 * f(a + h) - f(a + h + h)) / (h + h);
        }

        static public double Derivative2sc(
            double a, double h, Func<double, double> f)
        {
            return (f(a - h) - 2.0 * f(a) + f(a + h)) / (h + h);
        }

        static public double Derivative2sf(
            double a, double h, Func<double, double> f)
        {
            return (f(a) - 2.0 * f(a + h) + f(a + h + h)) / (h + h);
        }
    }
}

Adams-Moulton Predictor Corrector Method to Solve a One-Dimensional Ordinary Differential Equation Translated from FORTRAN 77 Code by James Pate Williams, Jr.

using System;
using System.Collections.Generic;
using System.ComponentModel;
using System.Data;
using System.Drawing;
using System.Linq;
using System.Text;
using System.Threading.Tasks;
using System.Windows.Forms;

namespace AdamsMoultonMethod1
{
    public partial class Form1 : Form
    {
        public Form1()
        {
            InitializeComponent();
        }

        private double Solution(double x)
        {
            return Math.Exp(x) - 1.0 - x;
        }
        private void button1_Click(object sender, EventArgs e)
        {
            int numberSteps = (int)numericUpDown1.Value;
            AdamsMoulton.AdamsMoultonMethod(
                numberSteps, Solution, textBox1);
        }

        private void button2_Click(object sender, EventArgs e)
        {
            textBox1.Text = string.Empty;
        }
    }
}
// Adams-Moulton Method translated from FORTRAN 77
// source code found in "Elementary Numerical Analysis:
// An Algorithmic Approach" by S. D. Conte and Carl de
// Boor. Translator: James Pate Williams, Jr. (c)
// August 18, 2023

using System;
using System.Windows.Forms;

namespace AdamsMoultonMethod1
{
    public struct Point
    {
        public double x, y;
    }
    class AdamsMoulton
    {
        static private string FormatNumber(double x)
        {
            return x.ToString("E11").PadLeft(12);
        }
        static private string FormatLine(
            int n, double x, double y, double delta, double error)
        {
            return
                n.ToString("D2") + " " +
                FormatNumber(x) + " " +
                FormatNumber(y) + " " +
                FormatNumber(delta) + " " +
                FormatNumber(error) + "\r\n";
        }
        static public void AdamsMoultonMethod(
            int numberSteps, Func<double, double> solution,
            TextBox textBox)
        {
            double h = 1.0 / numberSteps;
            double xn = 0.0, yn = 0.0, yofxn;
            double xBegin = 0.0, yBegin = 0.0;
            double fnPredict, ynPredict;
            double delta = 0.0, error = 0.0;
            double[] f = new double[numberSteps];
            int n = 0;

            textBox.Text += "n\txn\tyn\tdelta\terror\r\n";
            textBox.Text += FormatLine(n, xn, yn, delta, error);
            f[1] = xBegin + yBegin;

            for (n = 1; n <= 3; n++)
            {
                xn = xBegin + n * h;
                yn = solution(xn);
                f[n + 1] = xn + yn;
                textBox.Text += FormatLine(n, xn, yn, delta, error);
            }

            for (n = 4; n <= numberSteps; n++)
            {
                ynPredict =
                    yn + h / 24.0 * (55.0 * f[4] - 59.0 * f[3] +
                    37.0 * f[2] - 9.0 * f[1]);
                xn = xBegin + n * h;
                fnPredict = xn + ynPredict;
                yn += h / 24.0 * (9.0 * fnPredict + 19.0 * f[4]
                    - 5.0 * f[3] + f[2]);
                delta = (yn - ynPredict) / 14.0;
                f[1] = f[2];
                f[2] = f[3];
                f[3] = f[4];
                f[4] = xn + yn;
                yofxn = solution(xn);
                error = yn - yofxn;
                textBox.Text += FormatLine(n, xn, yn, delta, error);
            }
        }
    }
}

Determinant Calculations: Bareiss Algorithm and Gaussian Elimination by James Pate Williams, Jr.

Below are three screenshots of two methods of calculating the determinant of a matrix, namely the Bareiss Algorithm and Gaussian Elimination:

using System;
using System.Diagnostics;
using System.Windows.Forms;

namespace MatrixInverseComparison
{
    public partial class MainForm : Form
    {
        public MainForm()
        {
            InitializeComponent();
        }
        static private string FormatNumber(double x)
        {
            string result = string.Empty;

            if (x > 0)
                result += x.ToString("F5").PadLeft(10);
            else
                result += x.ToString("F5").PadLeft(10);

            return result;
        }

        private void MultiplyPrintMatricies(
            double[,] A, double[,] B, int n)
        {
            double[,] I = new double[n, n];

            textBox1.Text += "Matrix Product:\r\n";

            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                {
                    double sum = 0.0;

                    for (int k = 0; k < n; k++)
                        sum += A[i, k] * B[k, j];

                    I[i, j] = sum;
                }
            }

            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                {
                    textBox1.Text += FormatNumber(I[i, j]) + " ";
                }

                textBox1.Text += "\r\n";
            }
        }

        private void PrintMatrix(string title, double[,] A, int n)
        {
            textBox1.Text += title + "\r\n";

            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                {
                    textBox1.Text += FormatNumber(A[i, j]) + " ";
                }

                textBox1.Text += "\r\n";
            }
        }

        private void Compute(double[,] MI, int n)
        {
            double determinantGE = 1;
            double[] b = new double[n];
            double[] x = new double[n];
            double[,] MB1 = new double[n, n];
            double[,] MB2 = new double[n, n];
            double[,] MG = new double[n, n];
            double[,] MS = new double[n, n];
            double[,] IG = new double[n, n];
            double[,] IS = new double[n, n];
            int[] pivot = new int[n];
            Stopwatch sw = new();
            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                    MB1[i, j] = MB2[i, j] = MG[i, j] = MS[i, j] = MI[i, j];
            }
            PrintMatrix("Initial Matrix: ", MI, n);
            sw.Start();
            int flag = DirectMethods.Factor(MG, n, pivot);
            if (flag != 0)
            {
                for (int i = 0; i < n; i++)
                    determinantGE *= MG[i, i];
                determinantGE *= flag;
            }
            sw.Stop();
            PrintMatrix("Gaussian Elimination Final:", MG, n);
            for (int i = 0; i < n; i++)
                b[i] = 0;
            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                {
                    b[j] = 1.0;
                    DirectMethods.Substitute(MG, b, x, n, pivot);
                    for (int k = 0; k < n; k++)
                        IG[k, j] = x[k];
                    b[j] = 0.0;
                }
            }
            PrintMatrix("Gaussian Elimination Inverse:", IG, n);
            textBox1.Text += "Determinant: " +
                FormatNumber(determinantGE) + "\r\n";
            MultiplyPrintMatricies(IG, MI, n);
            textBox1.Text += "Runtime (MS) = " +
                sw.ElapsedMilliseconds + "\r\n";
            sw.Start();
            double determinant1 = BareissAlgorithm.Determinant1(MB1, n);
            sw.Stop();
            PrintMatrix("Bareiss Algorithm Final 1:", MB1, n);
            textBox1.Text += "Determinant: " +
                FormatNumber(determinant1) + "\r\n";
            textBox1.Text += "Runtime (MS) = " +
                sw.ElapsedMilliseconds + "\r\n";
            sw.Start();
            double determinant2 = BareissAlgorithm.Determinant2(MB2, n);
            sw.Stop();
            PrintMatrix("Bareiss Algorithm Final 2:", MB2, n);
            textBox1.Text += "Determinant: " +
                FormatNumber(determinant2) + "\r\n";
            textBox1.Text += "Runtime (MS) = " +
                sw.ElapsedMilliseconds + "\r\n";
        }
        private void button1_Click(object sender, EventArgs e)
        {
            int n = (int)numericUpDown1.Value;
            int seed = (int)numericUpDown2.Value;
            double[,] A = new double[n, n];
            Random random = new Random(seed);

            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                {
                    double q = n * random.NextDouble();

                    while (q == 0.0)
                        q = n * random.NextDouble();

                    A[i, j] = q;
                }
            }
            
            Compute(A, n);
        }

        private void button2_Click(object sender, EventArgs e)
        {
            textBox1.Text = string.Empty;
        }
    }
}
using System;

namespace MatrixInverseComparison
{
    public class DirectMethods
    {
        // Substitute and Factor translated from FORTRAN 77
        // source code found in "Elementary Numerical Analysis:
        // An Algorithmic Approach" by S. D. Conte and Carl de
        // Boor. Translator: James Pate Williams, Jr. (c)
        // August 14 - 17, 2023
        static public void Substitute(
            double[,] w,
            double[] b,
            double[] x,
            int n,
            int[] pivot)
        {
            double sum;
            int i, j, n1 = n - 1;

            if (n == 1)
            {
                x[0] = b[0] / w[0, 0];
                return;
            }

            // forward substitution
            x[0] = b[pivot[0]];

            for (i = 0; i < n; i++)
            {
                for (j = 0, sum = 0.0; j < i; j++)
                    sum += w[i, j] * x[j];
                x[i] = b[pivot[i]] - sum;
            }

            // backward substitution
            x[n1] /= w[n1, n1];

            for (i = n - 2; i >= 0; i--)
            {
                for (j = i + 1, sum = 0.0; j < n; j++)
                    sum += w[i, j] * x[j];
                x[i] = (x[i] - sum) / w[i, i];
            }
        }

        // Factor returns +1 if an even number of exchanges
        // Factor returns -1 if an odd  number of exchanges
        // Factor retrurn 0  if matrix is singular
        static public int Factor(
            double[,] w, int n, int[] pivot)
        // returns 0 if matrix is singular
        {
            double awikod, col_max, ratio, row_max, temp;
            double[] d = new double[n];
            int flag = 1, i, i_star, j, k;

            for (i = 0; i < n; i++)
            {
                pivot[i] = i;
                row_max = 0;
                for (j = 0; j < n; j++)
                    row_max = Math.Max(row_max, Math.Abs(w[i, j]));
                if (row_max == 0)
                {
                    flag = 0;
                    row_max = 1;
                }
                d[i] = row_max;
            }
            if (n <= 1)
                return flag;
            // factorization
            for (k = 0; k < n - 1; k++)
            {
                // determine pivot row the row i_star
                col_max = Math.Abs(w[k, k]) / d[k];
                i_star = k;
                for (i = k + 1; i < n; i++)
                {
                    awikod = Math.Abs(w[i, k]) / d[i];
                    if (awikod > col_max)
                    {
                        col_max = awikod;
                        i_star = i;
                    }
                }
                if (col_max == 0)
                    flag = 0;
                else
                {
                    if (i_star > k)
                    {
                        // make k the pivot row by
                        // interchanging with i_star
                        flag *= -1;
                        i = pivot[i_star];
                        pivot[i_star] = pivot[k];
                        pivot[k] = i;
                        temp = d[i_star];
                        d[i_star] = d[k];
                        d[k] = temp;
                        for (j = 0; j < n; j++)
                        {
                            temp = w[i_star, j];
                            w[i_star, j] = w[k, j];
                            w[k, j] = temp;
                        }
                    }
                    // eliminate x[k]
                    for (i = k + 1; i < n; i++)
                    {
                        w[i, k] /= w[k, k];
                        ratio = w[i, k];
                        for (j = k + 1; j < n; j++)
                            w[i, j] -= ratio * w[k, j];
                    }
                }
            }

            if (w[n - 1, n - 1] == 0)
                flag = 0;

            return flag;
        }
    }
}
namespace MatrixInverseComparison
{
    // One implementation is based on https://en.wikipedia.org/wiki/Bareiss_algorithm
    // Another perhaps better implementation is found on the following webpage
    // https://cs.stackexchange.com/questions/124759/determinant-calculation-bareiss-vs-gauss-algorithm
    class BareissAlgorithm
    {
        static public double Determinant1(double[,] M, int n)
        {
            double M00;

            for (int k = 0; k < n; k++)
            {
                if (k - 1 == -1)
                    M00 = 1;
                else
                    M00 = M[k - 1, k - 1];

                for (int i = k + 1; i < n; i++)
                {
                    for (int j = k + 1; j < n; j++)
                    {
                        M[i, j] = (
                            M[i, j] * M[k, k] -
                            M[i, k] * M[k, j]) / M00;
                    }
                }
            }

            return M[n - 1, n - 1];
        }

        static public double Determinant2(double[,] A, int dim)
        {
            if (dim <= 0)
            {
                return 0;
            }

            double sign = 1;

            for (int k = 0; k < dim - 1; k++)
            {
                //Pivot - row swap needed
                if (A[k, k] == 0)
                {
                    int m;
                    for (m = k + 1; m < dim; m++)
                    {
                        if (A[m, k] != 0)
                        {
                            double[] tempRow = new double[dim];

                            for (int i = 0; i < dim; i++)
                                tempRow[i] = A[m, i];
                            for (int i = 0; i < dim; i++)
                                A[m, i] = A[k, i];
                            for (int i = 0; i < dim; i++)
                                A[k, i] = tempRow[i];
                            sign = -sign;
                            break;
                        }
                    }
                    //No entries != 0 found in column k -> det = 0
                    if (m == dim)
                    {
                        return 0;
                    }
                }
                //Apply formula
                for (int i = k + 1; i < dim; i++)
                {
                    for (int j = k + 1; j < dim; j++)
                    {
                        A[i, j] = A[k, k] * A[i, j] - A[i, k] * A[k, j];

                        if (k >= 1)
                        {
                            A[i, j] /= A[k - 1, k - 1];
                        }
                    }
                }
            }

            return sign * A[dim - 1, dim - 1];
        }
    }
}

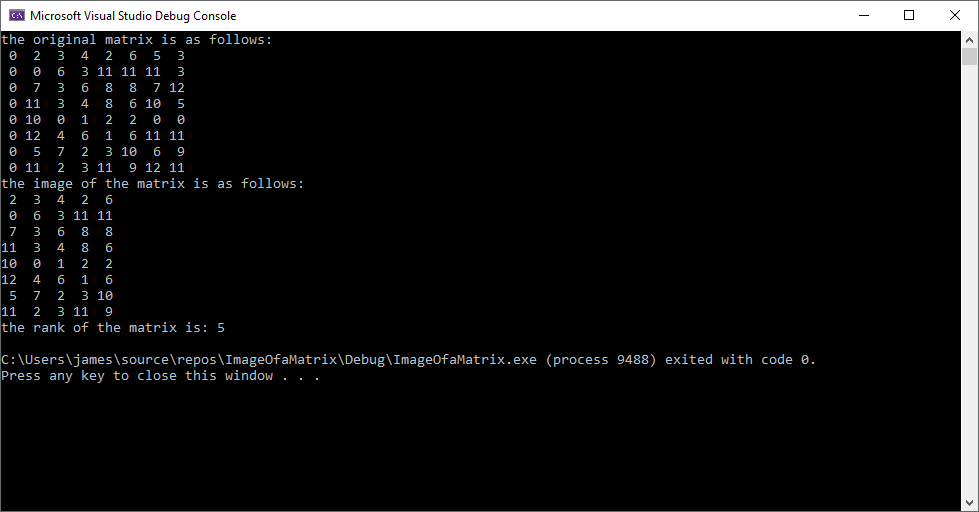
Blast from the Past 1997 Image of a Matrix by James Pate Williams, Jr.

/*
  Author:  Pate Williams (c) 1997

  "Algorithm 2.3.2 (Image of a Matrix). Given an
  m by n matrix M = (m[i][i]) with 1 <= i <= m and
  1 <= j <= n having coefficients in the field K,
  this algorithm outputs a basis of the image of
  M, i. e. vector space spanned by the columns of
  M." -Henri Cohen- See "A Course in Computational
  Algebraic Number Theory" by Henri Cohen pages
  58-59. We specialize the code to the field Zp.
*/

#include <stdio.h>
#include <stdlib.h>

long** create_matrix(long m, long n)
{
    long i, ** matrix = (long**)calloc(m, sizeof(long*));

    if (!matrix) {
        fprintf(stderr, "fatal error\ninsufficient memory\n");
        fprintf(stderr, "from create_matrix\n");
        exit(1);
    }
    for (i = 0; i < m; i++) {
        matrix[i] = (long*)calloc(n, sizeof(long));
        if (!matrix[i]) {
            fprintf(stderr, "fatal error\ninsufficient memory\n");
            fprintf(stderr, "from create_matrix\n");
            exit(1);
        }
    }
    return matrix;
}

void delete_matrix(long m, long** matrix)
{
    long i;

    for (i = 0; i < m; i++) free(matrix[i]);
    free(matrix);
}

void Euclid_extended(long a, long b, long* u,
    long* v, long* d)
{
    long q, t1, t3, v1, v3;

    *u = 1, * d = a;
    if (b == 0) {
        *v = 0;
        return;
    }
    v1 = 0, v3 = b;
#ifdef DEBUG
    printf("----------------------------------\n");
    printf(" q    t3   *u   *d   t1   v1   v3\n");
    printf("----------------------------------\n");
#endif
    while (v3 != 0) {
        q = *d / v3;
        t3 = *d - q * v3;
        t1 = *u - q * v1;
        *u = v1, * d = v3;
#ifdef DEBUG
        printf("%4ld %4ld %4ld ", q, t3, *u);
        printf("%4ld %4ld %4ld %4ld\n", *d, t1, v1, v3);
#endif
        v1 = t1, v3 = t3;
    }
    *v = (*d - a * *u) / b;
#ifdef DEBUG
    printf("----------------------------------\n");
#endif
}

long inv(long number, long modulus)
{
    long d, u, v;

    Euclid_extended(number, modulus, &u, &v, &d);
    if (d == 1) return u;
    return 0;
}

void image(long m, long n, long p,
    long** M, long** X, long* r)
{
    int found;
    long D, i, j, k, s;
    long* c = (long*)calloc(m, sizeof(long));
    long* d = (long*)calloc(n, sizeof(long));
    long** N = create_matrix(m, n);

    if (!c || !d) {
        fprintf(stderr, "fatal error\ninsufficient memory\n");
        fprintf(stderr, "from kernel\n");
        exit(1);
    }
    for (i = 0; i < m; i++) {
        c[i] = -1;
        for (j = 0; j < n; j++) N[i][j] = M[i][j];
    }
    *r = 0;
    for (k = 0; k < n; k++) {
        found = 0, j = 0;
        while (!found && j < m) {
            found = M[j][k] != 0 && c[j] == -1;
            if (!found) j++;
        }
        if (found) {
            D = p - inv(M[j][k], p);
            M[j][k] = p - 1;
            for (s = k + 1; s < n; s++)
                M[j][s] = (D * M[j][s]) % p;
            for (i = 0; i < m; i++) {
                if (i != j) {
                    D = M[i][k];
                    M[i][k] = 0;
                    for (s = k + 1; s < n; s++) {
                        M[i][s] = (M[i][s] + D * M[j][s]) % p;
                        if (M[i][s] < 0) M[i][s] += p;
                    }
                }
            }
            c[j] = k;
            d[k] = j;
        }
        else {
            *r = *r + 1;
            d[k] = -1;
        }
    }
    for (j = 0; j < m; j++) {
        if (c[j] != -1) {
            for (i = 0; i < n; i++) {
                if (i < m) X[i][j] = N[i][c[j]];
                else X[i][j] = 0;
            }
        }
    }
    delete_matrix(m, N);
    free(c);
    free(d);
}

void print_matrix(long m, long n, long** a)
{
    long i, j;

    for (i = 0; i < m; i++) {
        for (j = 0; j < n; j++)
            printf("%2ld ", a[i][j]);
        printf("\n");
    }
}

int main(void)
{
    long i, j, m = 8, n = 8, p = 13, r;
    long a[8][8] = { {0,  0,  0,  0,  0,  0,  0,  0},
                    {2,  0,  7, 11, 10, 12,  5, 11},
                    {3,  6,  3,  3,  0,  4,  7,  2},
                    {4,  3,  6,  4,  1,  6,  2,  3},
                    {2, 11,  8,  8,  2,  1,  3, 11},
                    {6, 11,  8,  6,  2,  6, 10,  9},
                    {5, 11,  7, 10,  0, 11,  6, 12},
                    {3,  3, 12,  5,  0, 11,  9, 11} };
    long** M = create_matrix(m, n);
    long** X = create_matrix(n, n);

    for (i = 0; i < m; i++)
        for (j = 0; j < n; j++)
            M[i][j] = a[j][i];
    printf("the original matrix is as follows:\n");
    print_matrix(m, n, M);
    image(m, n, p, M, X, &r);
    printf("the image of the matrix is as follows:\n");
    print_matrix(n, n - r, X);
    printf("the rank of the matrix is: %ld\n", n - r);
    delete_matrix(m, M);
    delete_matrix(n, X);
    return 0;
}
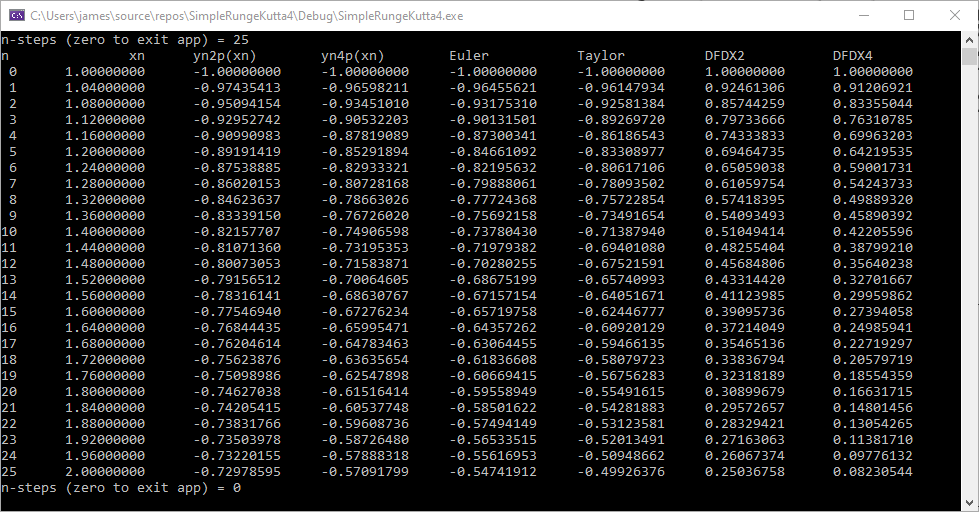
Part of a New Linear Algebra Package in C++ Implemented by James Pate Williams, Jr.

// Algorithms from "A Course in Computational
// Algebraic Number Theory" by Henri Cohen
// Implemented by James Pate Williams, Jr.
// Copyright (c) 2023 All Rights Reserved

#pragma once
#include "pch.h"

template<class T> class Matrix
{
public:
	size_t m, n;
	T** data;

	Matrix() { m = 0; n = 0; data = NULL; };
	Matrix(size_t m, size_t n)
	{
		this->m = m;
		this->n = n;
		data = new T*[m];

		if (data == NULL)
			exit(-300);

		for (size_t i = 0; i < m; i++)
		{
			data[i] = new T[n];

			if (data[i] == NULL)
				exit(-301);
		}
	};
	void OutputMatrix(
		fstream& outs, char fill, int precision, int width)
	{
		for (size_t i = 0; i < m; i++)
		{
			for (size_t j = 0; j < n; j++)
			{
				outs << setfill(fill) << setprecision(precision);
				outs << setw(width) << data[i][j] << '\t';
			}

			outs << endl;
		}
	};
};

template<class T> class Vector
{
public:
	size_t n;
	T* data;

	Vector() { n = 0; data = NULL; };
	Vector(size_t n)
	{
		this->n = n;
		data = new T[n];
	};
	void OutputVector(
		fstream& outs, char fill, int precision, int width)
	{
		for (size_t i = 0; i < n; i++)
		{
			outs << setfill(fill) << setprecision(precision);
			outs << setw(width) << data[i] << '\t';
		}

		outs << endl;
	};
};

class LinearAlgebra
{
public:
	bool initialized;
	size_t m, n;
	Matrix<double> M;
	Vector<double> B;

	LinearAlgebra() { 
		initialized = false;
		m = 0; n = 0;
		M.data = NULL;
		B.data = NULL;
	};
	LinearAlgebra(size_t m, size_t n) {
		initialized = false;
		this->m = m;
		this->n = n;
		this->M.m = m;
		this->M.n = n;
		this->B.n = n;
		this->M.data = new double*[m];
		this->B.data = new double[n];

		if (M.data != NULL)
		{
			for (size_t i = 0; i < m; i++)
			{
				this->M.data[i] = new double[n];

				for (size_t j = 0; j < n; j++)
					this->M.data[i][j] = 0;
			}
		}

		if (B.data != NULL)
		{
			this->B.data = new double[n];

			for (size_t i = 0; i < n; i++)
				this->B.data[i] = 0;
		}

		initialized = this->B.data != NULL && this->M.data != NULL;
	};
	LinearAlgebra(
		size_t m, size_t n,
		double** M,
		double* B)
	{
		this->m = m;
		this->n = n;
		this->M.m = m;
		this->M.n = n;
		this->M.data = new double*[m];

		if (M != NULL)
		{
			for (size_t i = 0; i < m; i++)
			{
				this->M.data[i] = new double[n];

				for (size_t j = 0; j < n; j++)
					this->M.data[i][j] = M[i][j];
			}
		}

		if (B != NULL)
		{
			this->B.data = new double[n];

			for (size_t i = 0; i < m; i++)
				this->B.data[i] = B[i];
		}

		initialized = this->B.data != NULL && this->M.data != NULL;
	}
	~LinearAlgebra()
	{
		M.m = m;
		M.n = n;
		B.n = n;

		if (B.data != NULL)
			delete[] B.data;

		for (size_t i = 0; i < m; i++)
			if (M.data[i] != NULL)
				delete[] M.data[i];

		if (M.data != NULL)
			delete[] M.data;
	}
	double DblDeterminant(size_t n, bool failure);
	Vector<double> DblGaussianElimination(
		bool& failure);
	// The following three methods are from the
	// textbook "Elementary Numerical Analysis
	// An Algorithmic Approach" by S. D. Conte
	// and Carl de Boor Translated from the
	// original FORTRAN by James Pate Williams, Jr.
	// Copyright (c) 2023 All Rights Reserved
	bool DblGaussianFactor(
		size_t n,
		Vector<int>& pivot);
	bool DblGaussianSolution(
		int n,
		Vector<double>& x,
		Vector<int>& pivot);
	bool DblSubstitution(
		size_t n,
		Vector<double>& x,
		Vector<int>& pivot);
	bool DblInverse(
		size_t n,
		Matrix<double>& A,
		Vector<int>& pivot);
};
#include "pch.h"
#include "LinearAlgebra.h"

double LinearAlgebra::DblDeterminant(
    size_t n, bool failure)
{
    double deter = 1;
    Vector<int> pivot(n);

    if (!initialized || m != n)
    {
        failure = true;
        return 0.0;
    }

    if (!DblGaussianFactor(n, pivot))
    {
        failure = true;
        return 0.0;
    }

    for (size_t i = 0; i < n; i++)
        deter *= M.data[i][i];

    return deter;
}

Vector<double> LinearAlgebra::DblGaussianElimination(
    bool& failure)
{
    double* C = new double[m];
    Vector<double> X(n);

    X.data = new double[n];

    if (X.data == NULL)
        exit(-200);

    if (!initialized)
    {
        failure = true;
        delete[] C;
        return X;
    }
    
    for (size_t i = 0; i < m; i++)
        C[i] = -1;

    failure = false;

    for (size_t j = 0; j < n; j++)
    {
        bool found = false;
        size_t i = j;

        while (i < n && !found)
        {
            if (M.data[i][j] != 0)
                found = true;
            else
                i++;
        }

        if (!found)
        {
            failure = true;
            break;
        }

        if (i > j)
        {
            for (size_t l = j; l < n; l++)
            {
                double t = M.data[i][l];
                M.data[i][l] = M.data[j][l];
                M.data[j][l] = t;
                t = B.data[i];
                B.data[i] = B.data[j];
                B.data[j] = t;
            }
        }

        double d = 1.0 / M.data[j][j];

        for (size_t k = j + 1; k < n; k++)
            C[k] = d * M.data[k][j];

        for (size_t k = j + 1; k < n; k++)
        {
            for (size_t l = j + 1; l < n; l++)
                M.data[k][l] = M.data[k][l] - C[k] * M.data[j][l];
            
            B.data[k] = B.data[k] - C[k] * B.data[j];
        }
    }

    for (int i = (int)n - 1; i >= 0; i--)
    {
        double sum = 0;

        for (size_t j = i + 1; j < n; j++)
            sum += M.data[i][j] * X.data[j];

        X.data[i] = (B.data[i] - sum) / M.data[i][i];
    }

    delete[] C;
    return X;
}

bool LinearAlgebra::DblGaussianFactor(
    size_t n,
    Vector<int>& pivot)
    // returns false if matrix is singular
{
    Vector<double> d(n);
    double awikod, col_max, ratio, row_max, temp;
    int flag = 1;
    size_t i_star, itemp;

    for (size_t i = 0; i < n; i++)
    {
        pivot.data[i] = i;
        row_max = 0;
        for (size_t j = 0; j < n; j++)
            row_max = max(row_max, abs(M.data[i][j]));
        if (row_max == 0)
        {
            flag = 0;
            row_max = 1;
        }
        d.data[i] = row_max;
    }
    if (n <= 1) return flag != 0;
    // factorization
    for (size_t k = 0; k < n - 1; k++)
    {
        // determine pivot row the row i_star
        col_max = abs(M.data[k][k]) / d.data[k];
        i_star = k;
        for (size_t i = k + 1; i < n; i++)
        {
            awikod = abs(M.data[i][k]) / d.data[i];
            if (awikod > col_max)
            {
                col_max = awikod;
                i_star = i;
            }
        }
        if (col_max == 0)
            flag = 0;
        else
        {
            if (i_star > k)
            {
                // make k the pivot row by
                // interchanging with i_star
                flag *= -1;
                itemp = pivot.data[i_star];
                pivot.data[i_star] = pivot.data[k];
                pivot.data[k] = itemp;
                temp = d.data[i_star];
                d.data[i_star] = d.data[k];
                d.data[k] = temp;
                for (size_t j = 0; j < n; j++)
                {
                    temp = M.data[i_star][j];
                    M.data[i_star][j] = M.data[k][j];
                    M.data[k][j] = temp;
                }
            }
            // eliminate x[k]
            for (size_t i = k + 1; i < n; i++)
            {
                M.data[i][k] /= M.data[k][k];
                ratio = M.data[i][k];
                for (size_t j = k + 1; j < n; j++)
                    M.data[i][j] -= ratio * M.data[k][j];
            }
        }

        if (M.data[n - 1][n - 1] == 0) flag = 0;
    }

    if (flag == 0)
        return false;

    return true;
}

bool LinearAlgebra::DblGaussianSolution(
    int n,
    Vector<double>& x,
    Vector<int>& pivot)
{
    if (!DblGaussianFactor(n, pivot))
        return false;

    return DblSubstitution(n, x, pivot);
}

bool LinearAlgebra::DblSubstitution(
    size_t n, Vector<double>& x,
    Vector<int>& pivot)
{
    double sum;
    size_t j, n1 = n - 1;

    if (n == 1)
    {
        x.data[0] = B.data[0] / M.data[0][0];
        return true;
    }

    // forward substitution

    x.data[0] = B.data[pivot.data[0]];

    for (int i = 1; i < (int)n; i++)
    {
        for (j = 0, sum = 0; j < (size_t)i; j++)
            sum += M.data[i][j] * x.data[j];

        x.data[i] = B.data[pivot.data[i]] - sum;
    }

    // backward substitution

    x.data[n1] /= M.data[n1][n1];

    for (int i = n - 2; i >= 0; i--)
    {
        double sum = 0.0;

        for (j = i + 1; j < n; j++)
            sum += M.data[i][j] * x.data[j];

        x.data[i] = (x.data[i] - sum) / M.data[i][i];
    }

    return true;
}

bool LinearAlgebra::DblInverse(
    size_t n,
    Matrix<double>& A,
    Vector<int>& pivot)
{
    Vector<double> x(n);

    if (!DblGaussianFactor(n, pivot))
        return false;

    for (size_t i = 0; i < n; i++)
    {
        for (size_t j = 0; j < n; j++)
            B.data[j] = 0;
    }
    
    for (size_t i = 0; i < n; i++)
    {
        B.data[i] = 1;

        if (!DblSubstitution(n, x, pivot))
            return false;

        B.data[i] = 0;

        for (size_t j = 0; j < n; j++)
           A.data[i][j] = x.data[pivot.data[j]];
    }

    return true;
}
/*
** Cohen's linear algebra test program
** Implemented by James Pate Williams, Jr.
** Copyright (c) 2023 All Rights Reserved
*/

#include "pch.h"
#include "LinearAlgebra.h"

double GetDblNumber(fstream& inps)
{
    char ch = inps.get();
    string numberStr;

    while (ch == ' ' || ch == '\t' || ch == '\r' || ch == '\n')
        ch = inps.get();

    while (ch == '+' || ch == '-' || ch == '.' ||
        ch >= '0' && ch <= '9')
    {
        numberStr += ch;
        ch = inps.get();
    }

    double x = atof(numberStr.c_str());
    return x;
}

int GetIntNumber(fstream& inps)
{
    char ch = inps.get();
    string numberStr;

    while (ch == ' ' || ch == '\t' || ch == '\r' || ch == '\n')
        ch = inps.get();

    while (ch == '+' || ch == '-' || ch >= '0' && ch <= '9')
    {
        numberStr += ch;
        ch = inps.get();
    }

    int x = atoi(numberStr.c_str());
    return x;
}

int main()
{
    fstream inps;

    inps.open("CLATestFile.txt", fstream::in);
    
    if (inps.fail())
    {
        cout << "Input file opening error!" << endl;
        return -1;
    }

    fstream outs;

    outs.open("CLAResuFile.txt", fstream::out | fstream::ate);

    if (outs.fail())
    {
        cout << "Output file opening error!" << endl;
        return -2;
    }

    size_t m, n;
    
    while (!inps.eof())
    {
        m = GetIntNumber(inps);

        if (inps.eof())
            return 0;

        if (m < 1)
        {
            cout << "The number of rows must be >= 1" << endl;
            return -100;
        }

        n = GetIntNumber(inps);

        if (n < 1)
        {
            cout << "The number of rows must be >= 1" << endl;
            return -101;
        }

        LinearAlgebra la(m, n);
        Matrix<double> copyM(m, n);
        Vector<double> copyB(n);

        for (size_t i = 0; i < m; i++)
        {
            for (size_t j = 0; j < n; j++)
            {
                double x = GetDblNumber(inps);

                la.M.data[i][j] = x;
                copyM.data[i][j] = x;
            }
        }

        for (size_t i = 0; i < n; i++)
        {
           la.B.data[i] = GetDblNumber(inps);
           copyB.data[i] = la.B.data[i];
        }

        bool failure = false;
        Vector<double> X = la.DblGaussianElimination(failure);

        if (!failure)
            X.OutputVector(outs, ' ', 5, 8);
        else
        {
            cout << "Cohen Gaussian elimination failure!" << endl;
            exit(-102);
        }


        for (size_t i = 0; i < m; i++)
        {
            la.B.data[i] = copyB.data[i];

            for (size_t j = 0; j < n; j++)
            {
                la.M.data[i][j] = copyM.data[i][j];
            }
        }

        Matrix<double> A(n, n);
        Vector<int> pivot(n);
        
        if (!la.DblGaussianSolution(n, X, pivot))
            exit(-103);

        X.OutputVector(outs, ' ', 5, 8);

        for (size_t i = 0; i < m; i++)
        {
            la.B.data[i] = copyB.data[i];

            for (size_t j = 0; j < n; j++)
            {
                la.M.data[i][j] = copyM.data[i][j];
            }
        }

        double deter = la.DblDeterminant(n, failure);

        outs << deter << endl;

        for (size_t i = 0; i < m; i++)
        {
            la.B.data[i] = copyB.data[i];

            for (size_t j = 0; j < n; j++)
            {
                la.M.data[i][j] = copyM.data[i][j];
            }
        }

        if (!la.DblInverse(n, A, pivot))
        {
            cout << "Conte Gaussian inverse matrix failure!" << endl;
            exit(-104);
        }

        else
            A.OutputMatrix(outs, ' ', 5, 8);
    }

    inps.close();
    outs.close();
}
2
2
1	1
1	2
7	11
2
2
1	1
1	3
7	11
2
2
6	3
4	8
5	6
2
2
5	3
10	4
8	6
3
3
2	1	-1
-3	-1	2
-2	1	2
8	-11	-3
       3	       4	
       3	       4	
1
       2	      -1	
      -1	       1	
       5	       2	
       5	       2	
2
     1.5	    -0.5	
    -0.5	     0.5	
 0.61111	 0.44444	
 0.61111	 0.44444	
36
 0.22222	-0.11111	
-0.083333	 0.16667	
    -1.4	       5	
    -1.4	       5	
-10
    -0.4	       1	
     0.3	    -0.5	
       2	       3	      -1	
       2	       3	      -1	
1
       4	       5	      -2	
       3	       4	      -2	
      -1	      -1	       1	

Multiple Integration Using Simpson’s Rule – Calculation of the Ground State Energies of the First Five Non-Relativistic Multiple Electron Atoms by James Pate Williams, Jr.

We calculate the ground state energies for Helium (Z = 2), Lithium (Z = 3), Beryllium (Z = 4), Boron (Z = 5), and Carbon (Z = 6). Currently, only three of the five atoms are implemented.

Multiple Integration Using Simpson’s Rule – Calculation of the Ground State of the Non-Relativistic Helium Atom by James Pate Williams, Jr.

The six-dimensional Cartesian coordinate wavefunction is calculated by the C# method:

public double Psi(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));
            double exp1 = Math.Exp(-alpha[0] * r1);
            double exp2 = Math.Exp(-alpha[1] * r2);
            double exp3 = Math.Exp(-alpha[2] * r12);

            return exp1 * exp2 * exp3;
        }

        public double Psi2(double[] x, double[] alpha)
        {
            double psi = Psi(x, alpha);

            return psi * psi;
        }

The wavefunction normalization method is:

public double Normalize(double[] alpha, int nSteps)
        {
            double[] lower = new double[6];
            double[] upper = new double[6];
            int[] steps = new int[6];

            lower[0] = 0.001;
            lower[1] = 0.001;
            lower[2] = 0.001;
            lower[3] = 0.001;
            lower[4] = 0.001;
            lower[5] = 0.001;

            upper[0] = 10.0;
            upper[1] = 10.0;
            upper[2] = 10.0;
            upper[3] = 10.0;
            upper[4] = 10.0;
            upper[5] = 10.0;

            for (int i = 0; i < 6; i++)
                steps[i] = nSteps;

            double norm = Math.Sqrt(integ.Integrate(
                lower, upper, alpha, Psi2, 6, steps));

            return norm;
        }

The two kinetic energy integrands are encapsulated in the following two methods:

private double Integrand1(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));
            double term = -2.0 * alpha[0] / r1 + alpha[0] * alpha[0];
            double mul1 = Math.Exp(-2.0 * alpha[0] * r1);
            double mul2 = Math.Exp(-2.0 * alpha[1] * r2);
            double mul3 = Math.Exp(-2.0 * alpha[2] * r12);

            return N * N * term * mul1 * mul2 * mul3;
        }

        private double Integrand2(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));
            double term = -2.0 * alpha[1] / r1 + alpha[1] * alpha[1];
            double mul1 = Math.Exp(-2.0 * alpha[0] * r1);
            double mul2 = Math.Exp(-2.0 * alpha[1] * r2);
            double mul3 = Math.Exp(-2.0 * alpha[2] * r12);

            return N * N * term * mul1 * mul2 * mul3;
        }

The two potential energy terms use the following two integrands:

private double Integrand3(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));
            double term = 1.0 / r1;
            double mul =
                Math.Exp(-2.0 * alpha[0] * r1) *
                Math.Exp(-2.0 * alpha[1] * r2) *
                Math.Exp(-2.0 * alpha[2] * r12);

            return -N * N * Z * term * mul;
        }

        private double Integrand4(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));
            double term = 1.0 / r2;
            double mul =
                Math.Exp(-2.0 * alpha[0] * r1) *
                Math.Exp(-2.0 * alpha[1] * r2) *
                Math.Exp(-2.0 * alpha[2] * r12);

            return -N * N * Z * term * mul;
        }

The electron-electron repulsion integrand is given by:

private double Integrand5(double[] x, double[] alpha)
        {
            double r1 = Math.Sqrt(x[0] * x[0] + x[1] * x[1] + x[2] * x[2]);
            double r2 = Math.Sqrt(x[3] * x[3] + x[4] * x[4] + x[5] * x[5]);
            double r12 = Math.Sqrt(Math.Pow(x[0] - x[3], 2.0) +
                Math.Pow(x[1] - x[4], 2.0) + Math.Pow(x[2] - x[5], 2.0));

            if (r12 == 0)
                r12 = 0.01;

            double term = 1.0 / r12;
            double mul =
                Math.Exp(-2.0 * alpha[0] * r1) *
                Math.Exp(-2.0 * alpha[1] * r2) *
                Math.Exp(-2.0 * alpha[2] * r12);

            return N * N * term * mul;
        }

The ground state non-relativistic energy is computed by the method:

public double Energy(double[] alpha, int nSteps, int Z)
        {
            double[] lower = new double[6];
            double[] upper = new double[6];
            int[] steps = new int[6];

            lower[0] = lower[1] = lower[2] = lower[3] = lower[4] = lower[5] = 0.001;
            upper[0] = upper[1] = upper[2] = upper[3] = upper[4] = upper[5] = 10.0;
            steps[0] = steps[1] = steps[2] = steps[3] = steps[4] = steps[5] = nSteps;

            N = Normalize(alpha, nSteps);

            this.Z = Z;

            double integ1 = integ.Integrate(lower, upper, alpha, Integrand1, 6, steps);
            double integ2 = integ.Integrate(lower, upper, alpha, Integrand2, 6, steps);
            double integ3 = integ.Integrate(lower, upper, alpha, Integrand3, 6, steps);
            double integ4 = integ.Integrate(lower, upper, alpha, Integrand4, 6, steps);
            double integ5 = integ.Integrate(lower, upper, alpha, Integrand5, 6, steps);
            
            return integ1 + integ2 - integ3 - integ4 + integ5;
        }

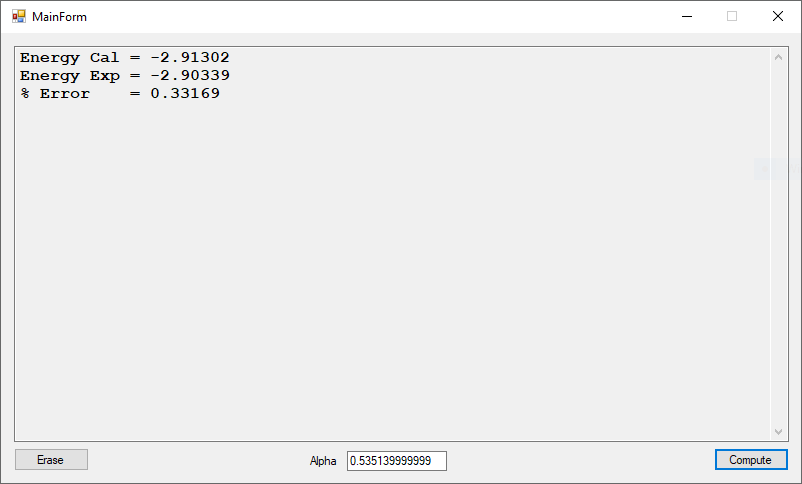
Using trial and error we calculate Alpha as: 0.535139999999

public double Integrate(double[] lower, double[] upper, double[] alpha,
            Func<double[], double[], double> f, int n, int[] steps)
        {
            double p = 1;
            double[] h = new double[n];
            double[] h2 = new double[n];
            double[] s = new double[n];
            double[] t = new double[n];
            double[] x = new double[n];
            double[] w = new double[n];

            for (int i = 0; i < n; i++)
            {
                h[i] = (upper[i] - lower[i]) / steps[i];
                h2[i] = 2.0 * h[i];
            }

            for (int i = 0; i < n; i++)
            {
                for (int j = 0; j < n; j++)
                    x[j] = lower[j];
                
                x[i] = lower[i] + h[i];

                for (int j = 1; j < steps[i]; j += 2)
                {
                    s[i] += f(x, alpha);
                    x[i] += h2[i];
                }

                for (int j = 0; j < n; j++)
                    x[j] = lower[j];

                x[i] = lower[i] + h2[i];

                for (int j = 2; j < steps[i]; j += 2)
                {
                    t[i] += f(x, alpha);
                    x[i] += h2[i];
                }

                w[i] = h[i] * (f(lower, alpha) + 4 * s[i] + 2 * t[i] + f(upper, alpha)) / 3.0;
            }

            for (int i = 0; i < n; i++)
                p *= w[i];

            return p;
        }

Romberg Integration of the Logarithmic Integral by James Pate Williams, Jr.

/*
Author:  Pate Williams (c) January 22, 1995
The following program is a translation of the FORTRAN
subprogram found in Elementary Numerical Analysis by
S. D. Conte and Carl de Boor pages 343-344. The program
uses Romberg extrapolation to find the integral of a
function.
*/

#include "stdafx.h"
#include <math.h>
#include <stdlib.h>
#include <time.h>
#include <stdio.h>

typedef long double real;

real t[10][10];

real f(real x)
{
	return(expl(-x * x));
}

real Li(real x)
{
	return(1.0 / logl(x));
}

real romberg(
	real a, real b, int start, int row,
	real(*f)(real))
{
	int i, k, m;
	real h, ratio, sum;

	m = start;
	h = (b - a) / m;
	sum = 0.5 * (f(a) + f(b));
	if (m > 1)
		for (i = 1; i < m; i++)
			sum += f(a + i * h);
	t[1][1] = h * sum;
	if (row < 2) return(t[1][1]);
	for (k = 2; k <= row; k++)
	{
		h = 0.5 * h;
		m *= 2;
		sum = 0.0;
		for (i = 1; i <= m; i += 2)
			sum += f(a + h * i);
		t[k][1] = 0.5 * t[k - 1][1] + sum * h;
		for (i = 1; i < k; i++)
		{
			t[k - 1][i] = t[k][i] - t[k - 1][i];
			t[k][i + 1] = t[k][i] - t[k - 1][i] /
				(powl(4.0, (real)i) - 1.0);
		}
	}
	if (row < 3) return(t[2][2]);
	for (k = 1; k <= row - 2; k++)
		for (i = 1; i <= k; i++)
		{
			if (t[k + 1][i] == 0.0)
				ratio = 0.0;
			else
				ratio = t[k][i] / t[k + 1][i];
			t[k][i] = ratio;
		}
	return(t[row][row - 1]);
}

int main(void)
{
	long double experimental = 0.7468241328124271;
	int row = 8;

	printf("first test\n");
	printf("Romberg integration of f(x) = exp(- x * x)\n");
	printf("Internet value = 0.7468241328124271\n");
	printf("from website = https://www.integral-calculator.com/\n");
	printf("Approximation\t\tPercent Difference\tSteps\tRuntime (s)\n");
	for (long steps = 100000; steps <= 900000; steps += 100000)
	{
		clock_t start = clock();
		long double trial = romberg(0.0, 1.0, steps, row, f);
		clock_t endTm = clock();
		long double runtime = ((long double)endTm - start) /
			CLOCKS_PER_SEC;
		long double pd = 100.0 * fabsl(experimental - trial) /
			(0.5 *(experimental + trial));
		printf("%16.15lf\t%16.15le\t%6d\t%4.3lf\n", 
			trial, pd, steps, runtime);
	}
	printf("second test\n");
	printf("Romberg integration of Li(x) = 1 / ln x between 2 and some n\n");
	printf("approximates the number of prime numbers between 2 and n\n");
	printf("n\t\tLi(n)\t\tSteps\tTime (s)\n");
	for (long n = 10; n <= 1000000000; n *= 10)
	{
		long steps = 1000000;

		clock_t start = clock();
		long double trial = romberg(2.0, n, steps, row, Li);
		clock_t endTm = clock();
		long double runtime = ((long double)endTm - start) /
			CLOCKS_PER_SEC;
		printf("%12ld\t%12.0lf\t%7ld\t%4.3lf\n",
			n, trial, steps, runtime);
	}
	return(0);
}

Set Implementation of Sieve of Eratosthenes by James Pate Williams, Jr.

/*
Author:  Pate Williams (c) January 20, 1995
The following is a translation of the Pascal program
sieve found in Pascalgorithms by Edwin D. Reilly and
Francis D. Federighi page 652. This program uses sets
to represent the sieve (see C Programming Language An
Applied Perspective by Lawrence Miller and Alec Qui-
lici pages 160 - 162).
*/
#include "stdafx.h"
#include <math.h>
#include <stdio.h>
#include <time.h>

#define _WORD_SIZE 32
#define _VECT_SIZE 31250000
#define SET_MIN    0
#define SET_MAX    1000000000

typedef long LONG;
typedef long SET[_VECT_SIZE];
typedef LONG ELEMENT;

SET set;

static LONG get_bit_pos(LONG *long_ptr, LONG *bit_ptr,
	ELEMENT element)
{
	*long_ptr = element / _WORD_SIZE;
	*bit_ptr = element % _WORD_SIZE;
	return(element >= SET_MIN && element <= SET_MAX);
}

static void set_bit(ELEMENT element, LONG inset)
{
	LONG bit, word;

	if (get_bit_pos(&word, &bit, element))
		inset ? set[word] |= (01 << bit) :
		set[word] &= ~(01 << bit);
}

static int get_bit(ELEMENT element)
{
	LONG bit, word;

	return(get_bit_pos(&word, &bit, element) ?
		(set[word] >> bit) & 01 : 0);
}

void set_Add(ELEMENT element)
{
	set_bit(element, 1);
}

void set_Del(ELEMENT element)
{
	set_bit(element, 0);
}

int set_Mem(ELEMENT element)
{
	return get_bit(element);
}

void primes(LONG n)
{
	LONG c, i, inc, k;
	double x;

	clock_t now = clock();
	set_Add(2);
	for (i = 3; i <= n; i++)
		if ((i + 1) % 2 == 0)
			set_Add(i);
		else
			set_Del(i);
	c = 3;
	do
	{
		i = c * c;
		inc = c + c;
		while (i <= n)
		{
			set_Del(i);
			i = i + inc;
		}
		c += 2;
		while (set_Mem(c) == 0) c += 1;
	} while (c * c <= n);
	k = 0;
	for (i = 2; i <= n; i++)
		if (set_Mem(i) == 1) k++;
	x = n / log(n) - 5.0;
	x = x + exp(1.0 + 0.15 * log(n) * sqrt(log(n)));
	clock_t later = clock();
	double runtime = (double)(later - now) / CLOCKS_PER_SEC;
	printf("%10ld\t%10ld\t%10.0lf\t%6.4lf\n",
		n, k, x, runtime);
}

int main(void)
{
	LONG n = 10L;

	printf("--------------------------------------------------------\n");
	printf("n\t\tprimes\t\ttheory\t\ttime (s)\n");
	printf("--------------------------------------------------------\n");
	do
	{
		primes(n);
		clock_t later = clock();
		n = 10L * n;
	} while (n < 1000000000);
	printf("--------------------------------------------------------\n");
	return(0);
}