// ThreeIntegrals.cpp
// Copyright (c) Sunday, October 11, 2026
// by James Pate Williams, Jr., BA, BS, MSwE, PhD
// Integrals due to Gauss, Cauchy, and Dirichlet

#include <chrono>
#include <iomanip>
#include <iostream>
#include <vector>

static double Gauss(double x)
{
    return exp(-x * x);
}

static double Cauchy(double x)
{
    return 1.0 / (x * x + 1.0);
}

static double Dirichlet(double x)
{
    return sin(x) / x;
}

static double SimpsonsRule(
    double a, double b, double(*fx)(double), int nSteps)
{
    double h = (b - a) / nSteps;
    double h2 = 2.0 * h;
    double s = 0.0;
    double t = 0.0;
    double x = a + h;

    for (int i = 1; i < nSteps; i += 2)
    {
        s += fx(x);
        x += h2;
    }

    x = a + h2;

    for (int i = 2; i < nSteps; i += 2)
    {
        t += fx(x);
        x += h2;
    }

    return h * (fx(a) + 4 * s + 2 * t + fx(b)) / 3.0;
}

static double ComputePi1(double bound)
{
    return SimpsonsRule(-bound, bound, Gauss, 16384);
}

static double ComputePi2(double bound, int nSteps)
{
    return 2.0 * SimpsonsRule(0.0, bound, Cauchy, nSteps);
}

static double ComputePi3(double bound, int nSteps)
{
    double zero = 1.0e-32;
    double integral1 = SimpsonsRule(-bound, -zero, Dirichlet, nSteps);
    double integral2 = SimpsonsRule(+zero, +bound, Dirichlet, nSteps);
    return integral1 + integral2;
}

static double nFactorial(int n)
{
    double factorial = 1.0;

    for (int i = 1; i <= n; i++)
        factorial *= i;

    return factorial;
}

typedef struct tagGene {
    int R; int nSteps;
} Gene, * PGene;

static double HillClimber(
    int fNumber, int generations, int population, Gene& gene)
{
    double pi = 4.0 * atan(1.0), pi2 = 0.0, pi3 = 0.0;
    std::vector<double> fitness(population);
    std::vector<std::vector<Gene>> genome;

    genome.resize(population);

    for (int i = 0; i < population; i++)
    {
        genome[i].resize(1);

        Gene g = { 0 };

        if (fNumber == 2)
        {
            g.R = rand() % 100000;
            g.nSteps = rand() % 100000;

            double pi2 = ComputePi2(g.R, g.nSteps);
            fitness[i] = fabs(pi - pi2);

            if (fitness[i] <= 1.0e-15)
            {
                gene = g;
                return pi2;
            }

            genome[i][0] = g;
        }

        else if (fNumber == 3)
        {
            g.R = rand() % 10000000;
            g.nSteps = rand() % 10000000;

            double pi3 = ComputePi3(g.R, g.nSteps);
            fitness[i] = fabs(pi - pi3);

            if (fitness[i] <= 1.0e-15)
            {
                gene = g;
                return pi3;
            }

            genome[i][0] = g;
        }
    }

    for (int g = 0; g < generations; g++)
    {
        double childFitness = DBL_MAX;
        int parent1 = rand() % population;
        int parent2 = rand() % population;
        int child = parent1 > parent2 ? parent1 : parent2;
        Gene childGene = genome[child][0];

        if (fNumber == 2)
        {
            pi2 = ComputePi2(childGene.R, childGene.nSteps);
            childFitness = fabs(pi - pi2);

            if (childFitness <= 1.0e-15)
            {
                gene = childGene;
                return childFitness;
            }
        }

        else if (fNumber == 3)
        {
            pi3 = ComputePi3(childGene.R, childGene.nSteps);
            childFitness = fabs(pi - pi3);

            if (childFitness <= 1.0e-15)
            {
                gene = childGene;
                return childFitness;
            }
        }

        double maxFitness = fitness[0];

        for (int i = 1; i < population; i++)
            if (fitness[i] > maxFitness)
                maxFitness = fitness[i];

        std::vector<int> maxIndices;

        for (int i = 0; i < population; i++)
            if (fitness[i] == maxFitness)
                maxIndices.push_back(i);

        int selection = maxIndices[rand() % maxIndices.size()];

        fitness[selection] = childFitness;
        genome[selection][0] = childGene;
    }

    double minFitness = fitness[0];

    for (int i = 1; i < population; i++)
        if (fitness[i] < minFitness)
            minFitness = fitness[i];

    std::vector<int> minIndices;

    for (int i = 0; i < population; i++)
        if (fitness[i] == minFitness)
            minIndices.push_back(i);

    int selection = minIndices[rand() % minIndices.size()];

    gene = genome[selection][0];

    if (fNumber == 2)
        return ComputePi2(gene.R, gene.nSteps);
    else if (fNumber == 3)
        return ComputePi3(gene.R, gene.nSteps);
    else
        return 0.0;
}

int main()
{
    Gene gene = { 0 };
    std::cout << std::fixed << std::setprecision(12);
    std::cout << "Function\t\tValue of Pi\tRuntime (mu-s)" << std::endl;
    auto start0 = std::chrono::high_resolution_clock::now();
    double pi0 = 4.0 * atan(1.0);
    auto stop0 = std::chrono::high_resolution_clock::now();
    auto duration0 = std::chrono::duration_cast<std::chrono::microseconds>(stop0 - start0);
    std::cout << "Pi [4 * atan(1)]   = " << pi0 << '\t' << duration0.count() << std::endl;
    // Gauss Integral
    auto start1 = std::chrono::high_resolution_clock::now();
    double pi1 = pow(ComputePi1(6.0e2), 2.0);
    auto stop1 = std::chrono::high_resolution_clock::now();
    auto duration1 = std::chrono::duration_cast<std::chrono::microseconds>(stop1 - start1);
    std::cout << "Gauss Integral     = " << pi1 << '\t' << duration1.count() << std::endl;
    // Cauchy Integral
    auto start2 = std::chrono::high_resolution_clock::now();
    double pi2 = HillClimber(2, 200000, 3000, gene);
    auto stop2 = std::chrono::high_resolution_clock::now();
    auto duration2 = std::chrono::duration_cast<std::chrono::microseconds>(stop2 - start2);
    std::cout << "Cauchy Integral    = " << pi2 << '\t' << duration2.count() << std::endl;
    // Dirichlet integral
    auto start3 = std::chrono::high_resolution_clock::now();
    double pi3 = HillClimber(3, 50000, 1000, gene);
    auto stop3 = std::chrono::high_resolution_clock::now();
    auto duration3 = std::chrono::duration_cast<std::chrono::microseconds>(stop3 - start3);
    std::cout << "Dirichlet Integral = " << pi3 << '\t' << duration3.count() << std::endl;
	return 0;
}
Blog Entry © Sunday, October 11, 2026, by James Pate Williams, Jr.
#pragma once

class Potential
{
public:
	static double Slot1SimpsonsRule(
		double a, double A, double B, int n, int nSteps,
		double(*fx)(double, double, int));
	static double SquareExact(
		double a, double b,
		double x, double y,
		int N);
	static void ComputeIntegrals(
		double a, int N, int nSteps, std::vector<double>& c);
	static double Slot1Exact(
		double a, double x, double y,
		int N, std::vector<double>& c);
	static void SquareFixedPoint(
		double a, double b,
		int Nx, int Ny, int iterations,
		std::vector<std::vector<double>>& U);
	static void Slot1FixedPoint(
		double a, double b,
		int Nx, int Ny, int iterations,
		std::vector<std::vector<double>>& U);
	static double Disk_f(double theta);
	static double Disk_a0(double theta);
	static double Disk_an(double c, double theta, int n);
	static double Disk_bn(double c, double theta, int n);
	static double SimpsonsRule_Disk_a0(int nSteps);
	static double SimpsonsRule_Disk_an(
		double c, int n, int nSteps);
	static double SimpsonsRule_Disk_bn(
		double c, int n, int nSteps);
	static double Disk_u(
		double c, double r, double theta,
		double a0, std::vector<double>& an,
		std::vector<double>& bn, int Nt,
		int nSteps);
};
#include "pch.h"
#include "Potential.h"

double Potential::Slot1SimpsonsRule(
    double a, double A, double B, int n, int nSteps,
    double(*fx)(double, double, int))
{
    double h = (B - A) / nSteps;
    double h2 = 2.0 * h;
    double s = 0.0;
    double t = 0.0;
    double x = A + h;

    for (int i = 1; i < nSteps; i += 2)
    {
        s += fx(a, x, n);
        x += h2;
    }

    x = A + h2;

    for (int i = 2; i < nSteps; i += 2)
    {
        t += fx(a, x, n);
        x += h2;
    }

    return h * (fx(a, A, n) + 4 * s + 2 * t + fx(a, B, n)) / 3.0;
}

double Potential::SquareExact(
    double a, double b,
    double x, double y,
    int N)
{
    double pi = 4.0 * atan(1.0);
    double sum = 0.0;

    for (int n = 1; n <= N; n++)
    {
        double l2 = pi * n / a;
        double s1 = sin(0.5 * n * pi) / (n * n);
        double s2 = sinh(l2 * y);
        double s3 = sinh(l2 * (b - y));
        double s4 = sinh(l2 * b);
        double s5 = sin(l2 * x);
        sum += s1 * ((s2 + s3) / s4) * s5;
    }

    return 8.0 * sum / (pi * pi);
}

double Slot1Integrand(double a, double x, int n)
{
    double pi = 4.0 * atan(1.0);
    return exp(-x) * sin(n * pi * x / a);
}

void Potential::ComputeIntegrals(
    double a, int N, int nSteps, std::vector<double>& c)
{
    c[0] = 0.0;

    for (int n = 1; n <= N; n++)
    {
        c[n] = 2.0 * Slot1SimpsonsRule(a, 0.0, a,
            n, nSteps, Slot1Integrand) / a;
    }
}

double Potential::Slot1Exact(
    double a, double x, double y,
    int N, std::vector<double>& c)
{
    double pi = 4.0 * atan(1.0), uxy = 0.0;

    for (int n = 1; n <= N; n++)
        uxy += c[n] * sin(n * pi * x / a) * exp(-n * pi * y / a);

    return uxy;
}

static double SquareF(double x)
{
    if (x > 0.0 && x < 0.5)
        return 2.0 * x;
    else if (x >= 0.5 && x < 1.0)
        return 2.0 - 2.0 * x;
    else
        return 0.0;
}

void Potential::SquareFixedPoint(
    double a, double b,
    int Nx, int Ny, int iterations,
    std::vector<std::vector<double>>& U)
{
    double deltaX = a / Nx, deltaY = b / Ny;

    U.resize(Nx + 1LL);

    for (int i = 0; i <= Nx; i++)
        U[i].resize(Ny + 1LL);

    for (int i = 0; i <= Ny; i++)
        U[0][i] = 0.0;

    for (int i = 1; i <= Ny; i++)
        U[Nx][i] = 0.0;

    for (int i = 0; i <= Nx; i++)
        U[i][0] = SquareF(i * deltaX);

    for (int i = 0; i <= Nx; i++)
        U[i][Ny] = SquareF(i * deltaX);

    for (int m = 0; m < iterations; m++)
    {
        for (int j = 1; j < Nx; j++)
        {
            for (int k = 1; k < Ny; k++)
                U[j][k] = 0.25 *
                (U[j + 1][k] + U[j - 1][k] +
                    U[j][k + 1] + U[j][k - 1]);
        }
    }
}

void Potential::Slot1FixedPoint(
    double a, double b,
    int Nx, int Ny, int iterations,
    std::vector<std::vector<double>>& U)
{
    double deltaX = a / Nx, deltaY = b / Ny;

    U.resize(Nx + 1);

    for (int i = 0; i <= Nx; i++)
        U[i].resize(Ny + 1, 0.0);

    for (int i = 0; i <= Nx; i++)
        U[i][0] = exp(-i * deltaX);

   for (int i = 0; i < iterations; i++)
    {
        for (int j = 1; j < Nx; j++)
        {
            for (int k = 1; k < Ny; k++)
                U[j][k] = 0.25 *
                (U[j + 1][k] + U[j - 1][k] +
                    U[j][k + 1] + U[j][k - 1]);
        }
    }
}

double Potential::Disk_f(double theta)
{
    return theta * theta;
}

double Potential::Disk_a0(double theta)
{
    double pi = 4.0 * atan(1.0);
    return Disk_f(theta);
}

double Potential::Disk_an(double c, double theta, int n)
{
    double pi = 4.0 * atan(1.0);
    return Disk_f(theta) * cos(n * theta) / (pi * pow(c, n));
}

double Potential::Disk_bn(double c, double theta, int n)
{
    double pi = 4.0 * atan(1.0);
    return Disk_f(theta) * cos(n * theta) / (pi * pow(c, n));
}

double Potential::SimpsonsRule_Disk_a0(int nSteps)
{
    double pi = 4.0 * atan(1.0);
    double h = (pi + pi) / nSteps;
    double h2 = 2.0 * h;
    double s = 0.0;
    double t = 0.0;
    double theta = -pi + h;

    for (int i = 1; i < nSteps; i += 2)
    {
        s += Disk_a0(theta);
        theta += h2;
    }

    theta = -pi + h2;

    for (int i = 2; i < nSteps; i += 2)
    {
        t += Disk_a0(theta);
        theta += h2;
    }

    return h * (Disk_a0(0.0) + 4 * s + 2 * t + Disk_a0(pi)) / 3.0;
}

double Potential::SimpsonsRule_Disk_an(
    double c, int n, int nSteps)
{
    double pi = 4.0 * atan(1.0);
    double h = (pi + pi) / nSteps;
    double h2 = 2.0 * h;
    double s = 0.0;
    double t = 0.0;
    double theta = -pi + h;

    for (int i = 1; i < nSteps; i += 2)
    {
        s += Disk_an(c, theta, n);
        theta += h2;
    }

    theta = -pi + h2;

    for (int i = 2; i < nSteps; i += 2)
    {
        t += Disk_an(c, theta, n);
        theta += h2;
    }

    double integral =
        h * (Disk_an(c, 0.0, n) + 4 * s + 2 * t +
             Disk_an(c, pi, n)) / 3.0;
    return integral / (pi * pow(c, n));
}

double Potential::SimpsonsRule_Disk_bn(
    double c, int n, int nSteps)
{
    double pi = 4.0 * atan(1.0);
    double h = (pi + pi) / nSteps;
    double h2 = 2.0 * h;
    double s = 0.0;
    double t = 0.0;
    double theta = -pi + h;

    for (int i = 1; i < nSteps; i += 2)
    {
        s += Disk_bn(c, theta, n);
        theta += h2;
    }

    theta = -pi + h2;

    for (int i = 2; i < nSteps; i += 2)
    {
        t += Disk_bn(c, theta, n);
        theta += h2;
    }

    double integral =
        h * (Disk_bn(c, 0.0, n) + 4 * s + 2 * t +
             Disk_bn(c, pi, n)) / 3.0;
    return integral / (pi * pow(c, n));
}

double Potential::Disk_u(
    double c, double r, double theta,
    double a0, std::vector<double>& an,
    std::vector<double>& bn, int Nt,
    int nSteps)
{
    double urt = a0;

    for (int n = 1; n <= Nt; n++)
    {
        urt += pow(r, n) * (
            an[n] * cos(n * theta) +
            bn[n] * sin(n * theta));
    }

    return urt;
}
Blog Entry © Tuesday, October 6, 2026, by James Pate Williams, Jr. Radial Basis Function Networks Results
Blog Entry © Sunday, October 4, 2026, by James Pate Williams, Jr. Riemannian Integration Tests
// Integration1dTests.cpp
// Copyright Saturday, October 3, 2026
// James Pate Williams, Jr. BA, BS, MSwE, PhD
// One-dimensional integration tests
// Our canonical integrands are x^3 exp(x) for
// x = 0 to x = 1 and x^3 sin(x) for x = 0 to x = pi

#include <iomanip>
#include <iostream>
using namespace std;

const int steps = 1024;

static double f1(double x)
{
	return x * x * x * exp(x);
}

static double f2(double x)
{
	return x * x * x * sin(x);
}

static double g1()
{
	return -2.0 * exp(1.0) + 6;
}

static double g2()
{
	double pi = 4.0 * atan(1.0);

	return -pi * pi * pi * cos(pi) + 6.0 * pi * cos(pi);
}

double TrapezoidalRule(
	int n, double a, double b, double(*fx)(double))
{
	double h = (b - a) / n;
	double s = 0.5 * (fx(a) + fx(b));
	double x = a + h;

	for (int i = 1; i < n; i++)
	{
		s += fx(x);
		x += h;
	}

	return h * s;
}

double SimpsonsRule(
	int n, double a, double b, double(*fx)(double))
{
	double h = (b - a) / n;
	double h2 = 2.0 * h;
	double s = 0.0;
	double t = 0.0;
	double x = a + h;

	for (int i = 1; i < n; i += 2)
	{
		s += fx(x);
		x += h2;
	}

	x = a + h2;

	for (int i = 2; i < n; i += 2)
	{
		t += fx(x);
		x += h2;
	}

	return h * (fx(a) + 4 * s + 2 * t + fx(b)) / 3.0;
}

static void PrintResult(double x)
{
	cout << setw(15) << fixed;
	cout << right << setprecision(12);
	cout << setfill(' ');
	cout << x;
}

static void PrintError(double x, double exact)
{
	cout << '\t';
	cout << setw(15) << fixed;
	cout << right << setprecision(12);
	cout << setfill(' ');
	cout << 100.0 * fabs(x - exact) /
		fabs(exact) << endl;
}

int main()
{
	double gAct1 = g1();
	double gAct2 = g2();
	double pi = 4.0 * atan(1.0);
	double trap1 = TrapezoidalRule(steps, 0.0, 1.0, f1);
	double simp1 = SimpsonsRule(steps, 0.0, 1.0, f1);
	double trap2 = TrapezoidalRule(steps, 0.0,pi, f2);
	double simp2 = SimpsonsRule(steps, 0.0, pi, f2);

	cout << "Functions are: " << endl;
	cout << "f1(x) = x ^ 3 * exp(x)" << endl;
	cout << "f2(x) = x ^ 3 * sin(x)" << endl;
	cout << "Trapezoidal and Simpson Use 1024 Steps" << endl;
	cout << "         Value           % Error";
	cout << endl;
	cout << "trap1 = ";
	PrintResult(trap1);
	PrintError(trap1, gAct1);
	cout << "simp1 = ";
	PrintResult(simp1);
	PrintError(simp1, gAct1);
	cout << "true1 = ";
	PrintResult(gAct1);
	cout << endl;
	cout << "trap2 = ";
	PrintResult(trap2);
	PrintError(trap2, gAct2);
	cout << "simp2 = ";
	PrintResult(simp2);
	PrintError(simp2, gAct2);
	cout << "true2 = ";
	PrintResult(gAct2);
	cout << endl;
	return 0;
}
Blog Entry © Saturday, October 3, 2026, by James Pate Williams, Jr. Planck’s Law Black Body Computations (C/C++ Code Translated from a 2021 C# App)
Blog Entry © Thursday, October 1, 2026, Classical Ballistics by James Pate Williams, Jr.
Blog Entry © Monday September 28, 2026, by James Pate Williams, Jr.
Blog Entry © Monday, September 21, 2026, by James Pate Williams, Jr. Using an Evolutionary Hill Climber for Function Optimization
// Minima.cpp : This file contains the 'main' function.
// Program execution begins and ends there.
// Copyright (c) Sunday, September 20, 2026
// by James Pate Williams, Jr., BA, BS, MSwE, PhD
// Evolutionary hill climber (c) 1999 by Pate

#include <iostream>
#include <time.h>
#include "Algorithms.h"

int main()
{
    while (true)
    {
        double minimum = 0.0, x0 = 0.0, y0 = 0.0;
        double f1 = 0.0, x = 0.0, y = 0.0;
        int evaluations = 0, maxIterations = 10000;
        int generation = 0, population = 0, option = 0;
        unsigned int seed = 1;

        std::cout << "== Menu == \r\n";
        std::cout << "1 Rastrigin Function\r\n";
        std::cout << "2 Ackley Function\r\n";
        std::cout << "3 Sphere Function\r\n";
        std::cout << "4 Rosenbrock Function\r\n";
        std::cout << "5 Beale Function\r\n";
        std::cout << "6 Exit\r\n";
        std::cout << "Option (1 - 6): ";
        std::cin >> option;

        if (option == 6)
            break;

        std::cout << "population = ";
        std::cin >> population;
        std::cout << "generation = ";
        std::cin >> generation;
        std::cout << "seed = ";
        std::cin >> seed;
        srand(seed);
        x0 = y0 = 10.0;

        clock_t clock0 = clock();

        if (option == 1)
        {
            Algorithms::HillClimber(
                population,
                generation,
                Algorithms::Rastrigin,
                x, y, minimum,
                evaluations,
                seed);
        }

        else if (option == 2)
        {
            Algorithms::HillClimber(
                population,
                generation,
                Algorithms::Ackley,
                x, y, minimum,
                evaluations,
                seed);
        }

        else if (option == 3)
        {
            Algorithms::HillClimber(
                population,
                generation,
                Algorithms::Sphere,
                x, y, minimum,
                evaluations,
                seed);
        }

        else if (option == 4)
        {
            Algorithms::HillClimber(
                population,
                generation,
                Algorithms::Rosenbrock,
                x, y, minimum,
                evaluations,
                seed);
        }

        else if (option == 5)
        {
            Algorithms::HillClimber(
                population,
                generation,
                Algorithms::Beale,
                x, y, minimum,
                evaluations,
                seed);
        }

        clock_t clock1 = clock();
        double runtime = (double)(clock1 - clock0) /
            CLOCKS_PER_SEC;

        std::cout << "x = " << x << std::endl;
        std::cout << "y = " << y << std::endl;
        std::cout << "f = " << minimum << std::endl;
        std::cout << "t = " << runtime << " seconds";
        std::cout << std::endl;
    }

    return 0;
}
#pragma once
class Algorithms
{
public:
	static double Rastrigin(double x, double y);
	static double Ackley(double x, double y);
	static double Sphere(double x, double y);
	static double Rosenbrock(double x, double y);
	static double Beale(double x, double y);

	static void HillClimber(
		int population,
		int generation,
		double(*f)(double, double),
		double& x, double& y,
		double& minimum,
		int& evaluations,
		unsigned int seed);
};
#include "Algorithms.h"
#include <vector>

double Algorithms::Rastrigin(double x, double y)
{
	double A = 10.0, pi = 4.0 * atan(1.0);
	return
		2.0 * A +
		x * x - A * cos(2.0 * pi * x) +
		y * y - A * cos(2.0 * pi * y);
}

double Algorithms::Ackley(double x, double y)
{
	double pi = 4.0 * atan(1.0);
	double xy = sqrt(0.5 * (x * x + y * y));
	double cx = cos(2.0 * pi * x);
	double cy = cos(2.0 * pi * y);
	double expf1 = -20.0 * exp(-0.2 * xy);
	double expf2 = -exp(0.5 * (cx + cy));
	return expf1 + expf2 + exp(1.0) + 20.0;
}

double Algorithms::Sphere(double x, double y)
{
	return x * x + y * y;
}

double Algorithms::Rosenbrock(double x, double y)
{
	return 100.0 * pow(y - x * x, 2.0) + pow(1.0 - x, 2.0);
}

double Algorithms::Beale(double x, double y)
{
	return
		pow(1.500 - x + x * y, 2.0) +
		pow(2.250 - x + x * y * y, 2.0) +
		pow(2.625 - x + x * y * y * y, 2.0);
}

void Algorithms::HillClimber(
	int population,
	int generation,
	double(*f)(double, double),
	double& x, double& y,
	double& minimum,
	int& evaluations,
	unsigned int seed)
{
	srand(seed);
	std::vector<double> fitness(population);
	std::vector<std::vector<double>> genes(
		population, std::vector<double>(2));

	for (int i = 0; i < population; i++)
	{
		genes[i][0] = (10.0 * rand()) / RAND_MAX;
		genes[i][1] = (10.0 * rand()) / RAND_MAX;
		fitness[i] = f(genes[i][0], genes[i][1]);
	}

	for (int i = 0; i < generation; i++)
	{
		int parent1 = rand() % population;
		int parent2 = rand() % population;
		int parent0 = parent1 > parent2 ? parent1 : parent2;
		int sign = rand() % 2 == 0 ? -1 : +1;
		double childGeneX = (10.0 * rand()) / RAND_MAX;
		double childGeneY = (10.0 * rand()) / RAND_MAX;
		double childFitness = f(childGeneX, childGeneY);
		double maxFitness = fitness[0];

		for (int i = 1; i < population; i++)
			if (fitness[i] > maxFitness)
				maxFitness = fitness[i];

		std::vector<int> maxIndex;

		for (int i = 0; i < population; i++)
			if (fitness[i] == maxFitness)
				maxIndex.push_back(i);

		int replace = maxIndex[rand() % maxIndex.size()];

		fitness[replace] = childFitness;
		genes[replace][0] = childGeneX;
		genes[replace][1] = childGeneY;
	}

	evaluations = generation + population;

	double minFitness = fitness[0];

	for (int i = 1; i < population; i++)
		if (fitness[i] < minFitness)
			minFitness = fitness[i];

	std::vector<int> minIndex;

	for (int i = 0; i < population; i++)
		if (fitness[i] == minFitness)
			minIndex.push_back(i);

	int replace = minIndex[rand() % minIndex.size()];
	minimum = fitness[replace];
	x = genes[replace][0];
	y = genes[replace][1];
}
Blog Entry © Monday, September 14, 2026, by James Pate Williams, Jr. Cardioid Curve Graph
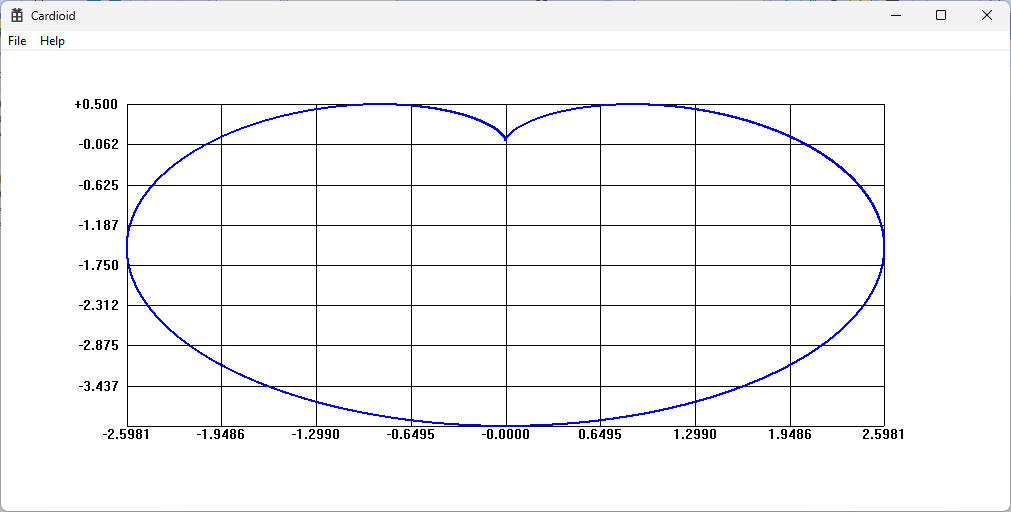
// Cardioid.cpp : Defines the entry point for the application.
// Copyright (c) Sunday, September 13, 2026
// by James Pate Williams, Jr. BA, BS, MSwE, PhD
// https://en.wikipedia.org/wiki/Cardioid

#include "framework.h"
#include "Cardioid.h"
#include <float.h>
#include <stdio.h>
#include <vector>

#define MAX_LOADSTRING 100

typedef struct tagPoint2d
{
    double x, y;
} Point2d, * PPoint2d;

// Global Variables:
HINSTANCE hInst;                                // current instance
WCHAR szTitle[MAX_LOADSTRING];                  // The title bar text
WCHAR szWindowClass[MAX_LOADSTRING];            // the main window class name
std::vector<Point2d> points;

// Forward declarations of functions included in this code module:
ATOM                MyRegisterClass(HINSTANCE hInstance);
BOOL                InitInstance(HINSTANCE, int);
LRESULT CALLBACK    WndProc(HWND, UINT, WPARAM, LPARAM);
INT_PTR CALLBACK    About(HWND, UINT, WPARAM, LPARAM);

int APIENTRY wWinMain(_In_ HINSTANCE hInstance,
                     _In_opt_ HINSTANCE hPrevInstance,
                     _In_ LPWSTR    lpCmdLine,
                     _In_ int       nCmdShow)
{
    UNREFERENCED_PARAMETER(hPrevInstance);
    UNREFERENCED_PARAMETER(lpCmdLine);

    // TODO: Place code here.

    // Initialize global strings
    LoadStringW(hInstance, IDS_APP_TITLE, szTitle, MAX_LOADSTRING);
    LoadStringW(hInstance, IDC_CARDIOID, szWindowClass, MAX_LOADSTRING);
    MyRegisterClass(hInstance);

    // Perform application initialization:
    if (!InitInstance (hInstance, nCmdShow))
    {
        return FALSE;
    }

    HACCEL hAccelTable = LoadAccelerators(hInstance, MAKEINTRESOURCE(IDC_CARDIOID));

    MSG msg;

    // Main message loop:
    while (GetMessage(&msg, nullptr, 0, 0))
    {
        if (!TranslateAccelerator(msg.hwnd, hAccelTable, &msg))
        {
            TranslateMessage(&msg);
            DispatchMessage(&msg);
        }
    }

    return (int) msg.wParam;
}

//
//  FUNCTION: MyRegisterClass()
//
//  PURPOSE: Registers the window class.
//
ATOM MyRegisterClass(HINSTANCE hInstance)
{
    WNDCLASSEXW wcex = { 0 };

    wcex.cbSize = sizeof(WNDCLASSEX);

    wcex.style          = CS_HREDRAW | CS_VREDRAW;
    wcex.lpfnWndProc    = WndProc;
    wcex.cbClsExtra     = 0;
    wcex.cbWndExtra     = 0;
    wcex.hInstance      = hInstance;
    wcex.hIcon          = LoadIcon(hInstance, MAKEINTRESOURCE(IDI_CARDIOID));
    wcex.hCursor        = LoadCursor(nullptr, IDC_ARROW);
    wcex.hbrBackground  = (HBRUSH)(COLOR_WINDOW+1);
    wcex.lpszMenuName   = MAKEINTRESOURCEW(IDC_CARDIOID);
    wcex.lpszClassName  = szWindowClass;
    wcex.hIconSm        = LoadIcon(wcex.hInstance, MAKEINTRESOURCE(IDI_SMALL));

    return RegisterClassExW(&wcex);
}

//
//   FUNCTION: InitInstance(HINSTANCE, int)
//
//   PURPOSE: Saves instance handle and creates main window
//
//   COMMENTS:
//
//        In this function, we save the instance handle in a global variable and
//        create and display the main program window.
//
BOOL InitInstance(HINSTANCE hInstance, int nCmdShow)
{
   hInst = hInstance; // Store instance handle in our global variable

   HWND hWnd = CreateWindowW(szWindowClass, szTitle, WS_OVERLAPPEDWINDOW,
      CW_USEDEFAULT, 0, CW_USEDEFAULT, 0, nullptr, nullptr, hInstance, nullptr);

   if (!hWnd)
   {
      return FALSE;
   }

   ShowWindow(hWnd, nCmdShow);
   UpdateWindow(hWnd);

   return TRUE;
}

static void FindMinMax(
    double& xMin, double& xMax,
    double& yMin, double& yMax)
{
    // uses global 2D double points structure

    xMin = yMin = DBL_MAX;
    xMax = yMax = DBL_MIN;

    for (size_t i = 0; i < points.size(); i++)
    {
        Point2d pt = points[i];
        double x = pt.x;
        double y = pt.y;

        if (x < xMin)
            xMin = x;
        if (x > xMax)
            xMax = x;
        if (y < yMin)
            yMin = y;
        if (y > yMax)
            yMax = y;
    }
}

static void DrawFormattedText(HDC hdc, char text[], RECT rect)
{
    // Draw the text with formatting options
    DrawTextA(hdc, text, -1, &rect, DT_SINGLELINE | DT_NOCLIP);
}

static void CreateCurve(double a, int n)
{
    double pi = 4.0 * atan(1.0), phi = 0.0;

    while (phi < 2.0 * pi)
    {
        double phi1 = 1.0 - cos(phi);
        double y = 2.0 * a * phi1 * cos(phi);
        double x = 2.0 * a * phi1 * sin(phi);
        Point2d pt = { 0, 0 };

        pt.x = x;
        pt.y = y;
        points.push_back(pt);
        phi += 0.001;
    }
}

//
//  FUNCTION: WndProc(HWND, UINT, WPARAM, LPARAM)
//
//  PURPOSE: Processes messages for the main window.
//
//  WM_COMMAND  - process the application menu
//  WM_PAINT    - Paint the main window
//  WM_DESTROY  - post a quit message and return
//
//
LRESULT CALLBACK WndProc(HWND hWnd, UINT message, WPARAM wParam, LPARAM lParam)
{
    switch (message)
    {
    case WM_COMMAND:
        {
            int wmId = LOWORD(wParam);
            // Parse the menu selections:
            switch (wmId)
            {
            case IDM_ABOUT:
                DialogBox(hInst, MAKEINTRESOURCE(IDD_ABOUTBOX), hWnd, About);
                break;
            case IDM_EXIT:
                DestroyWindow(hWnd);
                break;
            default:
                return DefWindowProc(hWnd, message, wParam, lParam);
            }
        }
        break;
    case WM_PAINT:
    {
        CreateCurve(1.0, 256);
        double h = 0, pi = 0, plm = 0, theta = 0;
        double xMax = 0, xMin = 0, yMax = 0, yMin = 0;
        FindMinMax(xMin, xMax, yMin, yMax);
        float xSpan = (float)(xMax - xMin);
        float ySpan = (float)(yMax - yMin);
        RECT rect = { };
        GetClientRect(hWnd, &rect);
        float width = (float)(rect.right - rect.left + 1);
        float height = (float)(rect.bottom - rect.top - 32 + 1);
        float sx0 = 2.0f * width / 16.0f;
        float sx1 = 14.0f * width / 16.0f;
        float sy0 = 2.0f * height / 16.0f;
        float sy1 = 14.0f * height / 16.0f;
        float deltaX = xSpan / 8.0f;
        float deltaY = ySpan / 8.0f;
        float xSlope = (sx1 - sx0) / xSpan;
        float xInter = (float)(sx0 - xSlope * xMin);
        float ySlope = (sy0 - sy1) / ySpan;
        float yInter = (float)(sy0 - ySlope * yMax);
        float px = 0, py = 0, sx = 0, sy = 0;
        PAINTSTRUCT ps;
        POINT wPt = { };
        HDC hdc = BeginPaint(hWnd, &ps);
        int i = 0;
        float x = (float)xMin;
        float y = (float)yMax;
        px = x;
        py = y;
        sx = xSlope * px + xInter;
        sy = ySlope * py + yInter;
        MoveToEx(hdc, (int)sx, (int)sy0, &wPt);
        char buffer[128] = { };

        while (i <= 8)
        {
            sx = xSlope * x + xInter;
            wPt.x = wPt.y = 0;
            MoveToEx(hdc, (int)sx, (int)sy0, &wPt);
            LineTo(hdc, (int)sx, (int)sy1);

            sprintf_s(buffer, "%5.4lf", x);
            SIZE size = { };
            GetTextExtentPoint32A(
                hdc,
                buffer,
                (int)strlen(buffer),
                &size);
            RECT textRect = { };
            textRect.left = (long)(sx - size.cx / 2.0f);
            textRect.right = (long)(sx + size.cx / 2.0f);
            textRect.top = (long)sy1;
            textRect.bottom = (long)(sy1 + size.cy / 2.0f);
            DrawFormattedText(hdc, buffer, textRect);
            x += deltaX;
            i++;
        }

        i = 0;
        y = (float)yMin;

        while (i <= 8)
        {
            sy = ySlope * y + yInter;
            wPt.x = wPt.y = 0;
            MoveToEx(hdc, (int)sx0, (int)sy, &wPt);
            LineTo(hdc, (int)sx, (int)sy);

            if (i != 0)
            {
                sprintf_s(buffer, "%+5.3lf", y);
                SIZE size = { };
                GetTextExtentPoint32A(
                    hdc,
                    buffer,
                    (int)strlen(buffer),
                    &size);
                RECT textRect = { };
                textRect.left = (long)(sx0 - size.cx - size.cx / 5.0f);
                textRect.right = (long)(sx0 - size.cx / 2.0f);
                textRect.top = (long)(sy - size.cy / 2.0f);
                textRect.bottom = (long)(sy + size.cy / 2.0f);
                DrawFormattedText(hdc, buffer, textRect);
            }

            y += deltaY;
            i++;
        }

        HGDIOBJ bPenNew = NULL;
        HGDIOBJ hPenOld = NULL;

        bPenNew = CreatePen(PS_SOLID, 2, RGB(0, 0, 255));
        hPenOld = SelectObject(hdc, bPenNew);

        px = (float)points[0].x;
        py = (float)points[0].y;
        sx = xSlope * px + xInter;
        sy = ySlope * py + yInter;
        wPt.x = wPt.y = 0;
        MoveToEx(hdc, (int)sx, (int)sy, &wPt);

        for (size_t j = 1; j < points.size(); j++)
        {
            px = (float)points[j].x;
            py = (float)points[j].y;
            sx = xSlope * px + xInter;
            sy = ySlope * py + yInter;
            LineTo(hdc, (int)sx, (int)sy);
        }

        SelectObject(hdc, hPenOld);
        DeleteObject(bPenNew);

        return (INT_PTR)FALSE;
    }
    break;
    case WM_DESTROY:
        PostQuitMessage(0);
        break;
    default:
        return DefWindowProc(hWnd, message, wParam, lParam);
    }
    return 0;
}

// Message handler for about box.
INT_PTR CALLBACK About(HWND hDlg, UINT message, WPARAM wParam, LPARAM lParam)
{
    UNREFERENCED_PARAMETER(lParam);
    switch (message)
    {
    case WM_INITDIALOG:
        return (INT_PTR)TRUE;

    case WM_COMMAND:
        if (LOWORD(wParam) == IDOK || LOWORD(wParam) == IDCANCEL)
        {
            EndDialog(hDlg, LOWORD(wParam));
            return (INT_PTR)TRUE;
        }
        break;
    }
    return (INT_PTR)FALSE;
}
Blog Entry © Monday – Thursday, September 7 – 10, 2026, by James Pate Williams, Jr. Solutions of Three Nonhomogeneous Second Order Linear Ordinary Differential Equation Boundary Value Problems and a Series Solution of the Bessel Function of the First Kind of Integer Eigenvalue (Order) of Zero
// FiniteDifference.cpp : This file contains the 'main' function.
// Program execution begins and ends there.
// Copyright (c) Wednesday, August 9, 2026
// by James Pate Williams, Jr., BA, BS, MSwE, PhD
// Reference: "Elementary Numerical Analysis an Algorithmic Approach
// Third Edition" © 1980 by S. D. Conte and Carl de Boor

#include <math.h>
#include <stdio.h>

#define MAX_ROWS 8192

double ac[MAX_ROWS];
double fv[MAX_ROWS];
double gv[MAX_ROWS];
double qv[MAX_ROWS];
double xv[MAX_ROWS];
double yv[MAX_ROWS];

double ta[MAX_ROWS];
double tb[MAX_ROWS];
double td[MAX_ROWS];
double tc[MAX_ROWS];
double tx[MAX_ROWS];

int SolveTridiagonal(int n)
{
    for (int k = 2; k <= n; k++)
    {
        if (td[k - 1] == 0)
            return 0;

        double m = ta[k] / td[k - 1];
        td[k] -= m * tc[k - 1];
        tb[k] -= m * tb[k - 1];
    }

    if (td[n] == 0)
        return 0;

    tx[n] = tb[n] / td[n];

    for (int k = n - 1; k >= 1; k--)
        tx[k] = (tb[k] - tc[k] * tx[k + 1]) / td[k];

    return 1;
}

double f1(double x)
{
	return 0.0;
}

double g1(double x)
{
	return -1.0;
}

double q1(double x)
{
	return 0.0;
}

double f2(double x)
{
	return 0.0;
}

double g2(double x)
{
	return 1.0;
}

double q2(double x)
{
	return 0.0;
}

double f3(double x)
{
	return x;
}

double g3(double x)
{
	return 1.0;
}

double q3(double x)
{
	return 2.0 * x;
}

double f4(double x)
{
	return 2.0;
}

double g4(double x)
{
	return 1.0;
}

double q4(double x)
{
	return x;
}

double f5(double x)
{
	return 1.0 / x;
}

double g5(double x)
{
	return 1.0;
}

double q5(double x)
{
	return 0.0;
}

double FD_Solution(
	double a,
	double b,
	double ya,
	double yb,
	double (*f)(double),
	double (*g)(double),
	double (*q)(double),
	int N)
{
	double h = (b - a) / N;

	for (int i = 1; i <= N - 1; i++)
	{
		xv[i] = a + i * h;
		fv[i] = f(xv[i]);
		gv[i] = g(xv[i]);
		qv[i] = q(xv[i]);
	}

	tb[1] = h * h * qv[1] - (1.0 - 0.5 * h * fv[1]) * ya;

	for (int i = 2; i <= N - 1; i++)
		tb[i] = h * h * qv[i];

	for (int i = 1; i <= N - 1; i++)
		td[i] = -2.0 + h * h * gv[i];

	for (int i = 1; i <= N - 2; i++)
		tc[i] = 1.0 + 0.5 * h * fv[i];

	for (int i = 2; i <= N - 1; i++)
		ta[i] = 1.0 - 0.5 * h * fv[i];

	tb[N - 1] = h * h * qv[N - 1] - (1.0 + 0.5 * h * fv[N - 1]) * yb;

	return SolveTridiagonal(N - 1);
}

double IS_Solution(
	double a,
	double b,
	double ya,
	double yb,
	double x)
{
	double A[13] = { 0 };

	A[0] = 1.0;
	A[1] = 0.0;
	A[2] = -0.25;
	A[3] = 0.0;
	A[4] = A[0] / 64.0;
	A[5] = 0.0;
	A[6] = -A[0] / (36.0 * 64.0);
	A[7] = 0.0;
	A[8] = A[0] / (64.0 * 36.0 * 64.0);
	A[9] = 0.0;
	A[10] = -A[8] / 100.0;
	A[11] = 0.0;
	A[12] = -A[10] / 144.0;

	double s = A[12];

	for (int i = 11; i >= 0; i--)
		s = s * x + A[i];

	return s;
}

int main()
{
	double h = 0.05, x0 = 0.0, x1 = 1.0, y0 = 0, y1 = 1.0;
	int N = (int)((x1 - x0) / h);
	double fd1 = FD_Solution(
		x0, x1, y0, y1, f1, g1, q1, N);
	FILE* file = 0;
	int errno = fopen_s(&file, "Chapter9.txt", "w");

	if (errno != 0)
		return -1;

	fprintf_s(file, "Example 9.1\r\n");
	fprintf_s(file, " x\tapproximate\texact\t\tpercent error\r\n");

	for (int i = 1; i < N; i++)
	{
		double exact = sinh(xv[i]) / sinh(1.0);
		double error = 100.0 * (fabs(tx[i] - exact) / fabs(exact));
		fprintf_s(file, "%3.2lf\t%11.10lf\t%11.10lf\t%11.10lf\r\n",
			xv[i], tx[i], exact, error);

	}

	h = 0.25;
	x0 = 0.0, x1 = 1.0, y0 = 0, y1 = 1.0;
	N = (int)((x1 - x0) / h);
	double fd2 = FD_Solution(
		x0, x1, y0, y1, f2, g2, q2, N);

	fprintf_s(file, "Exercise 9.1-1\r\n");
	fprintf_s(file, " x\tapprox\r\n");

	for (int i = 1; i < N; i++)
		fprintf_s(file, "%3.2lf\t%5.4lf\r\n", xv[i], tx[i]);

	h = 0.1;
	x0 = 0.0, x1 = 1.0, y0 = 1.0, y1 = 0.0;
	N = (int)((x1 - x0) / h);
	double fd3 = FD_Solution(
		x0, x1, y0, y1, f3, g3, q3, N);

	fprintf_s(file, "Exercise 9.1-3\r\n");
	fprintf_s(file, " x\t approximate\r\n");

	for (int i = 1; i < N; i++)
		fprintf_s(file, "%3.2lf\t%11.10lf\r\n", xv[i], tx[i]);

	h = 1.0 / 16.0;
	x0 = 0.0, x1 = 1.0, y0 = 0.0, y1 = 1.0;
	N = (int)((x1 - x0) / h);
	double fd4 = FD_Solution(
		x0, x1, y0, y1, f4, g4, q4, N);

	fprintf_s(file, "Exercise 9.1-4\r\n");
	fprintf_s(file, " x\t approximate\r\n");

	for (int i = 1; i < N; i++)
		fprintf_s(file, "%3.2lf\t%11.10lf\r\n", xv[i], tx[i]);

	h = 1.0 / 16.0;
	x0 = 0.0, x1 = 2.0, y0 = 1.0, y1 = 2.238907555e-01;
	N = (int)((x1 - x0) / h);
	double fd5 = FD_Solution(
		x0, x1, y0, y1, f5, g5, q5, N);

	fprintf_s(file, "Bessel Equation of Order Zero\r\n");
	fprintf_s(file, "Approximate Finite Difference Solution\r\n");

	fprintf_s(file, " x\t approximate\r\n");

	for (int i = 1; i < N; i++)
		fprintf_s(file, "%3.2lf\t%11.10lf\r\n", xv[i], tx[i]);

	fprintf_s(file, "Bessel Equation of Order Zero\r\n");
	fprintf_s(file, "Approximate Infinite Series Solution\r\n");

	fprintf_s(file, " x\t approximate\r\n");

	for (int i = 1; i < N; i++)
	{
		double x = x0 + i * h;
		fprintf_s(file, "%3.2lf\t%11.10lf\r\n", x,
			IS_Solution(x0, x1, y0, y1, x));
	}

    return 0;
}

